| Shayegan Omidshafiei
Alum Website
shayegan [at] mit [dot] edu
| |  | Sharing in Multiagent Reinforcement Learning
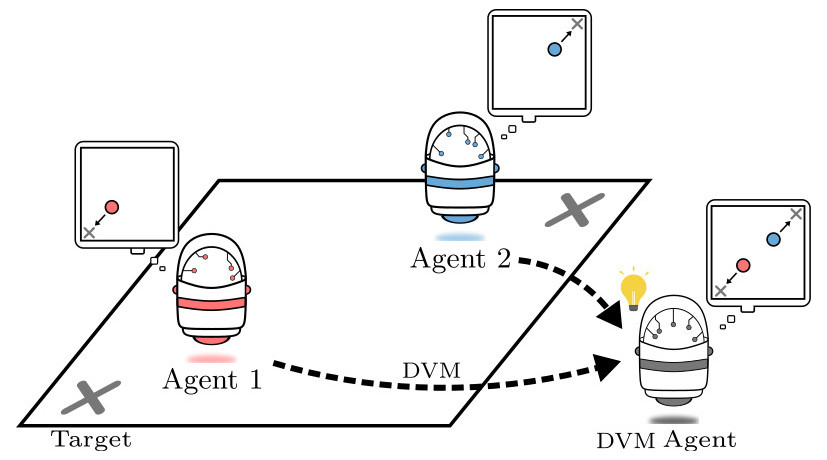
Samir Wadhwania, Dong-Ki Kim, Shayegan Omidshafiei, 2019
Sharing information during learning in multiagent environments can reduce the need for each agent to explore the entire state space, leading to reduced learning time. | 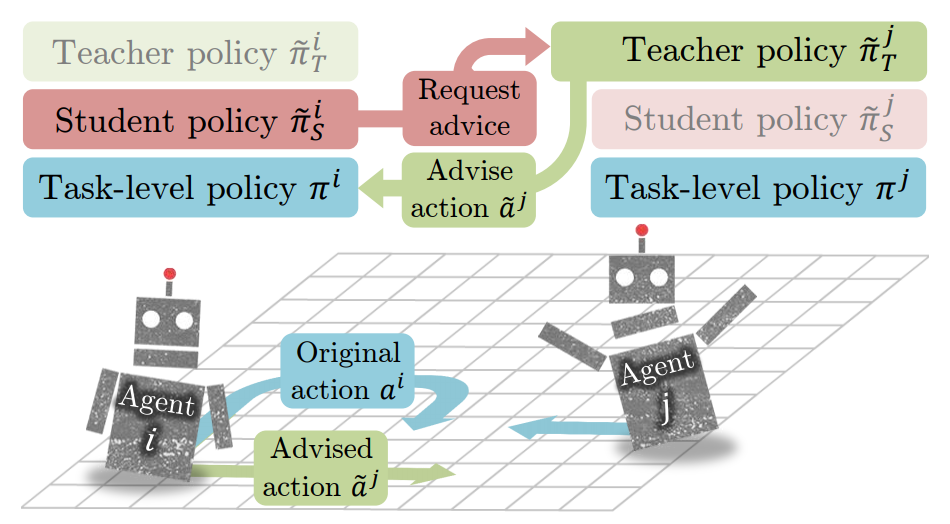 | Learning to Teach in Cooperative MARL
Dong-Ki Kim, Shayegan Omidshafiei, 2018
Our algorithm, Learning to Coordinate and Teach Reinforcement (LeCTR), addresses peer-to-peer teaching in cooperative multiagent reinforcement learning. | 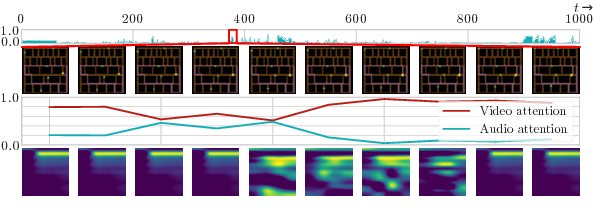 | Crossmodal Attentive Skill Learner
Shayegan Omidshafiei, Dong-Ki Kim, 2018
This work introduces the crossmodal learning paradigm and addresses the problem of learning in a high-dimensional domain with multiple sensory inputs. | 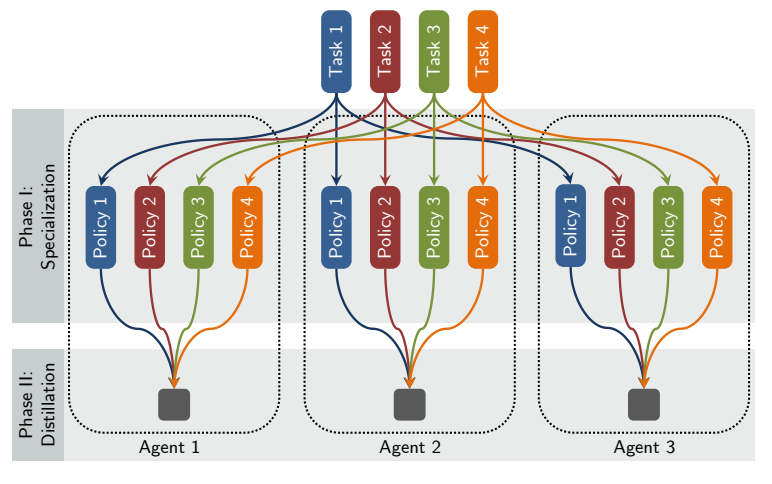 | Decentralized Multi-task Learning
Shayegan Omidshafiei, 2018
This work formalizes and addresses the problem of multi-task multiagent reinforcement learning under partial observability. | 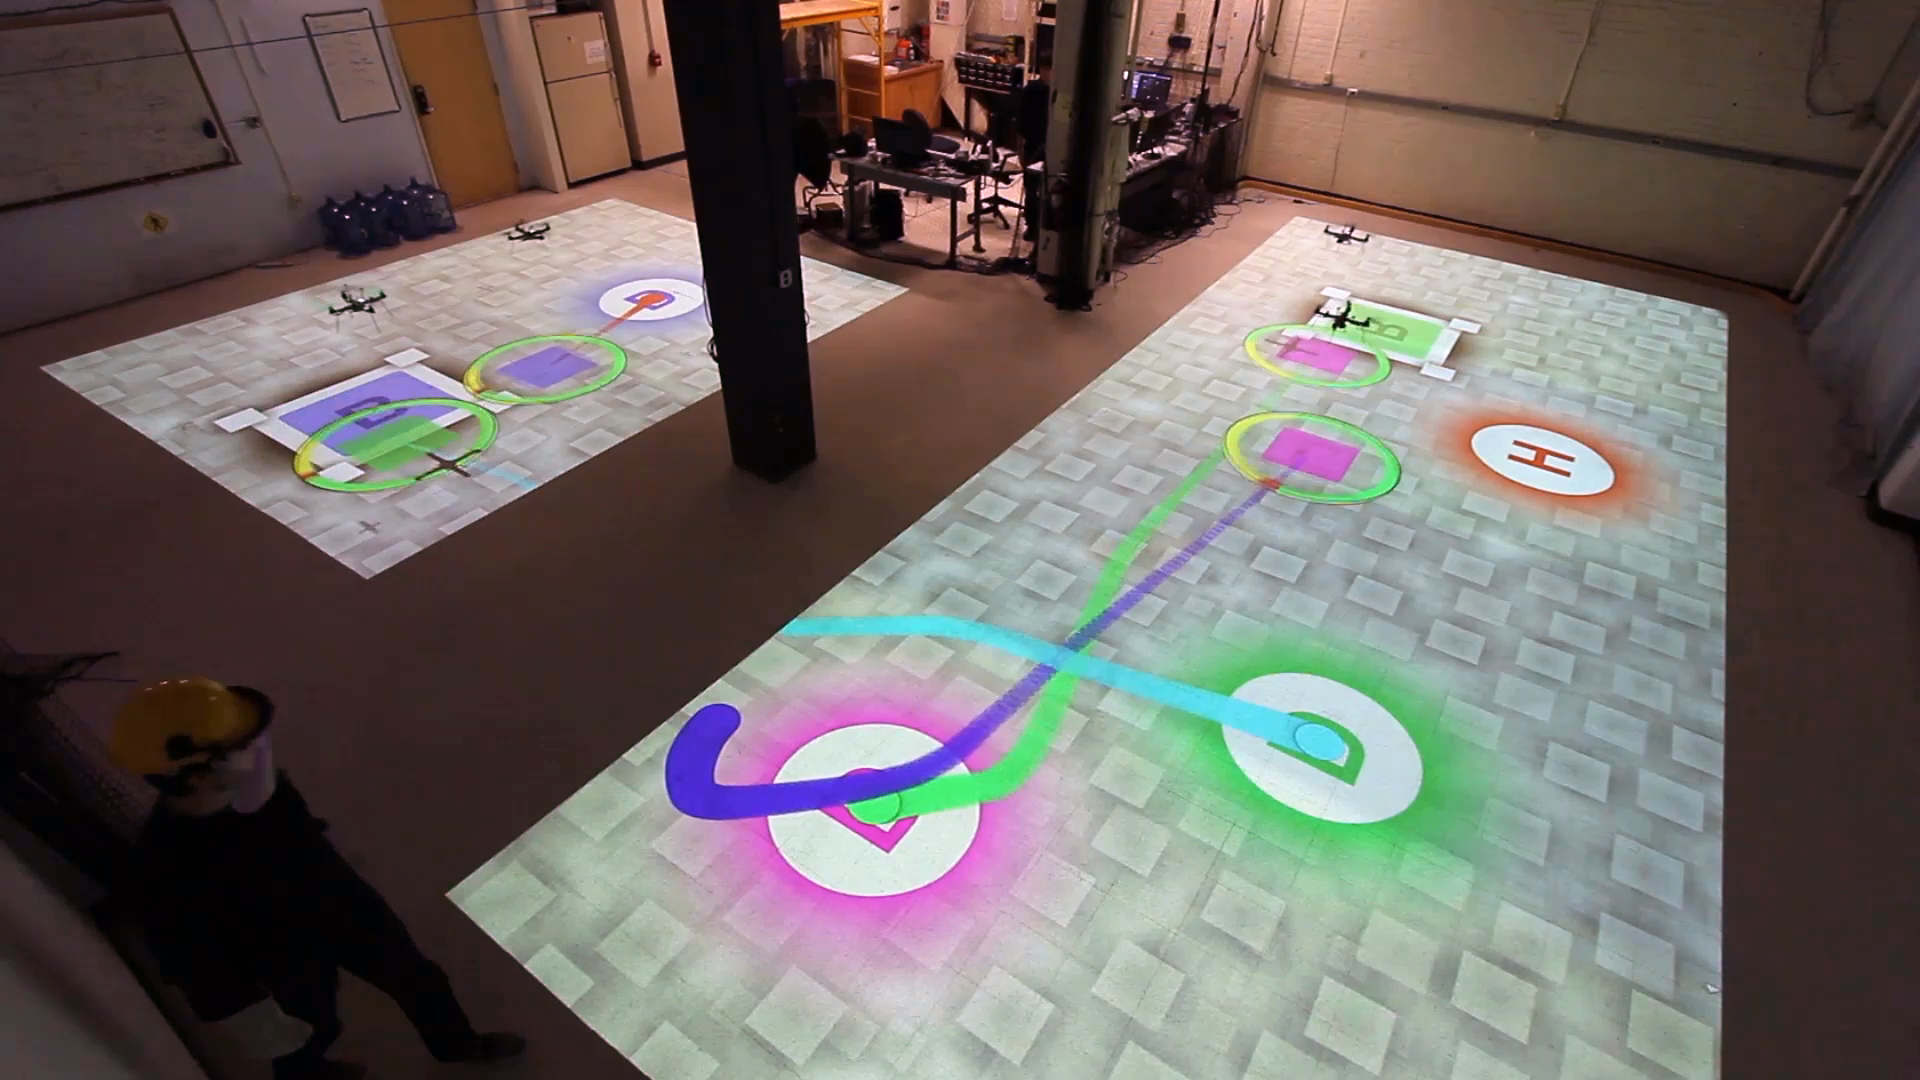 | Decentralized Control of Multi-Robot Partially Observable Markov Decision Processes using Belief Space Macro-actions
Shayegan Omidshafiei, Ali-akbar Ahga-mohammadi, Christopher Amato, Shih-Yuan Liu, Miao Liu, 2014
This work extends the Dec-POMDP model to the Decentralized Partially Observable Semi-Markov Decision Process (Dec-POSMDP) to take advantage of high-level representations that are natural for multi-robot problems and to facilitate scalable solutions to large discrete and continuous problems. | 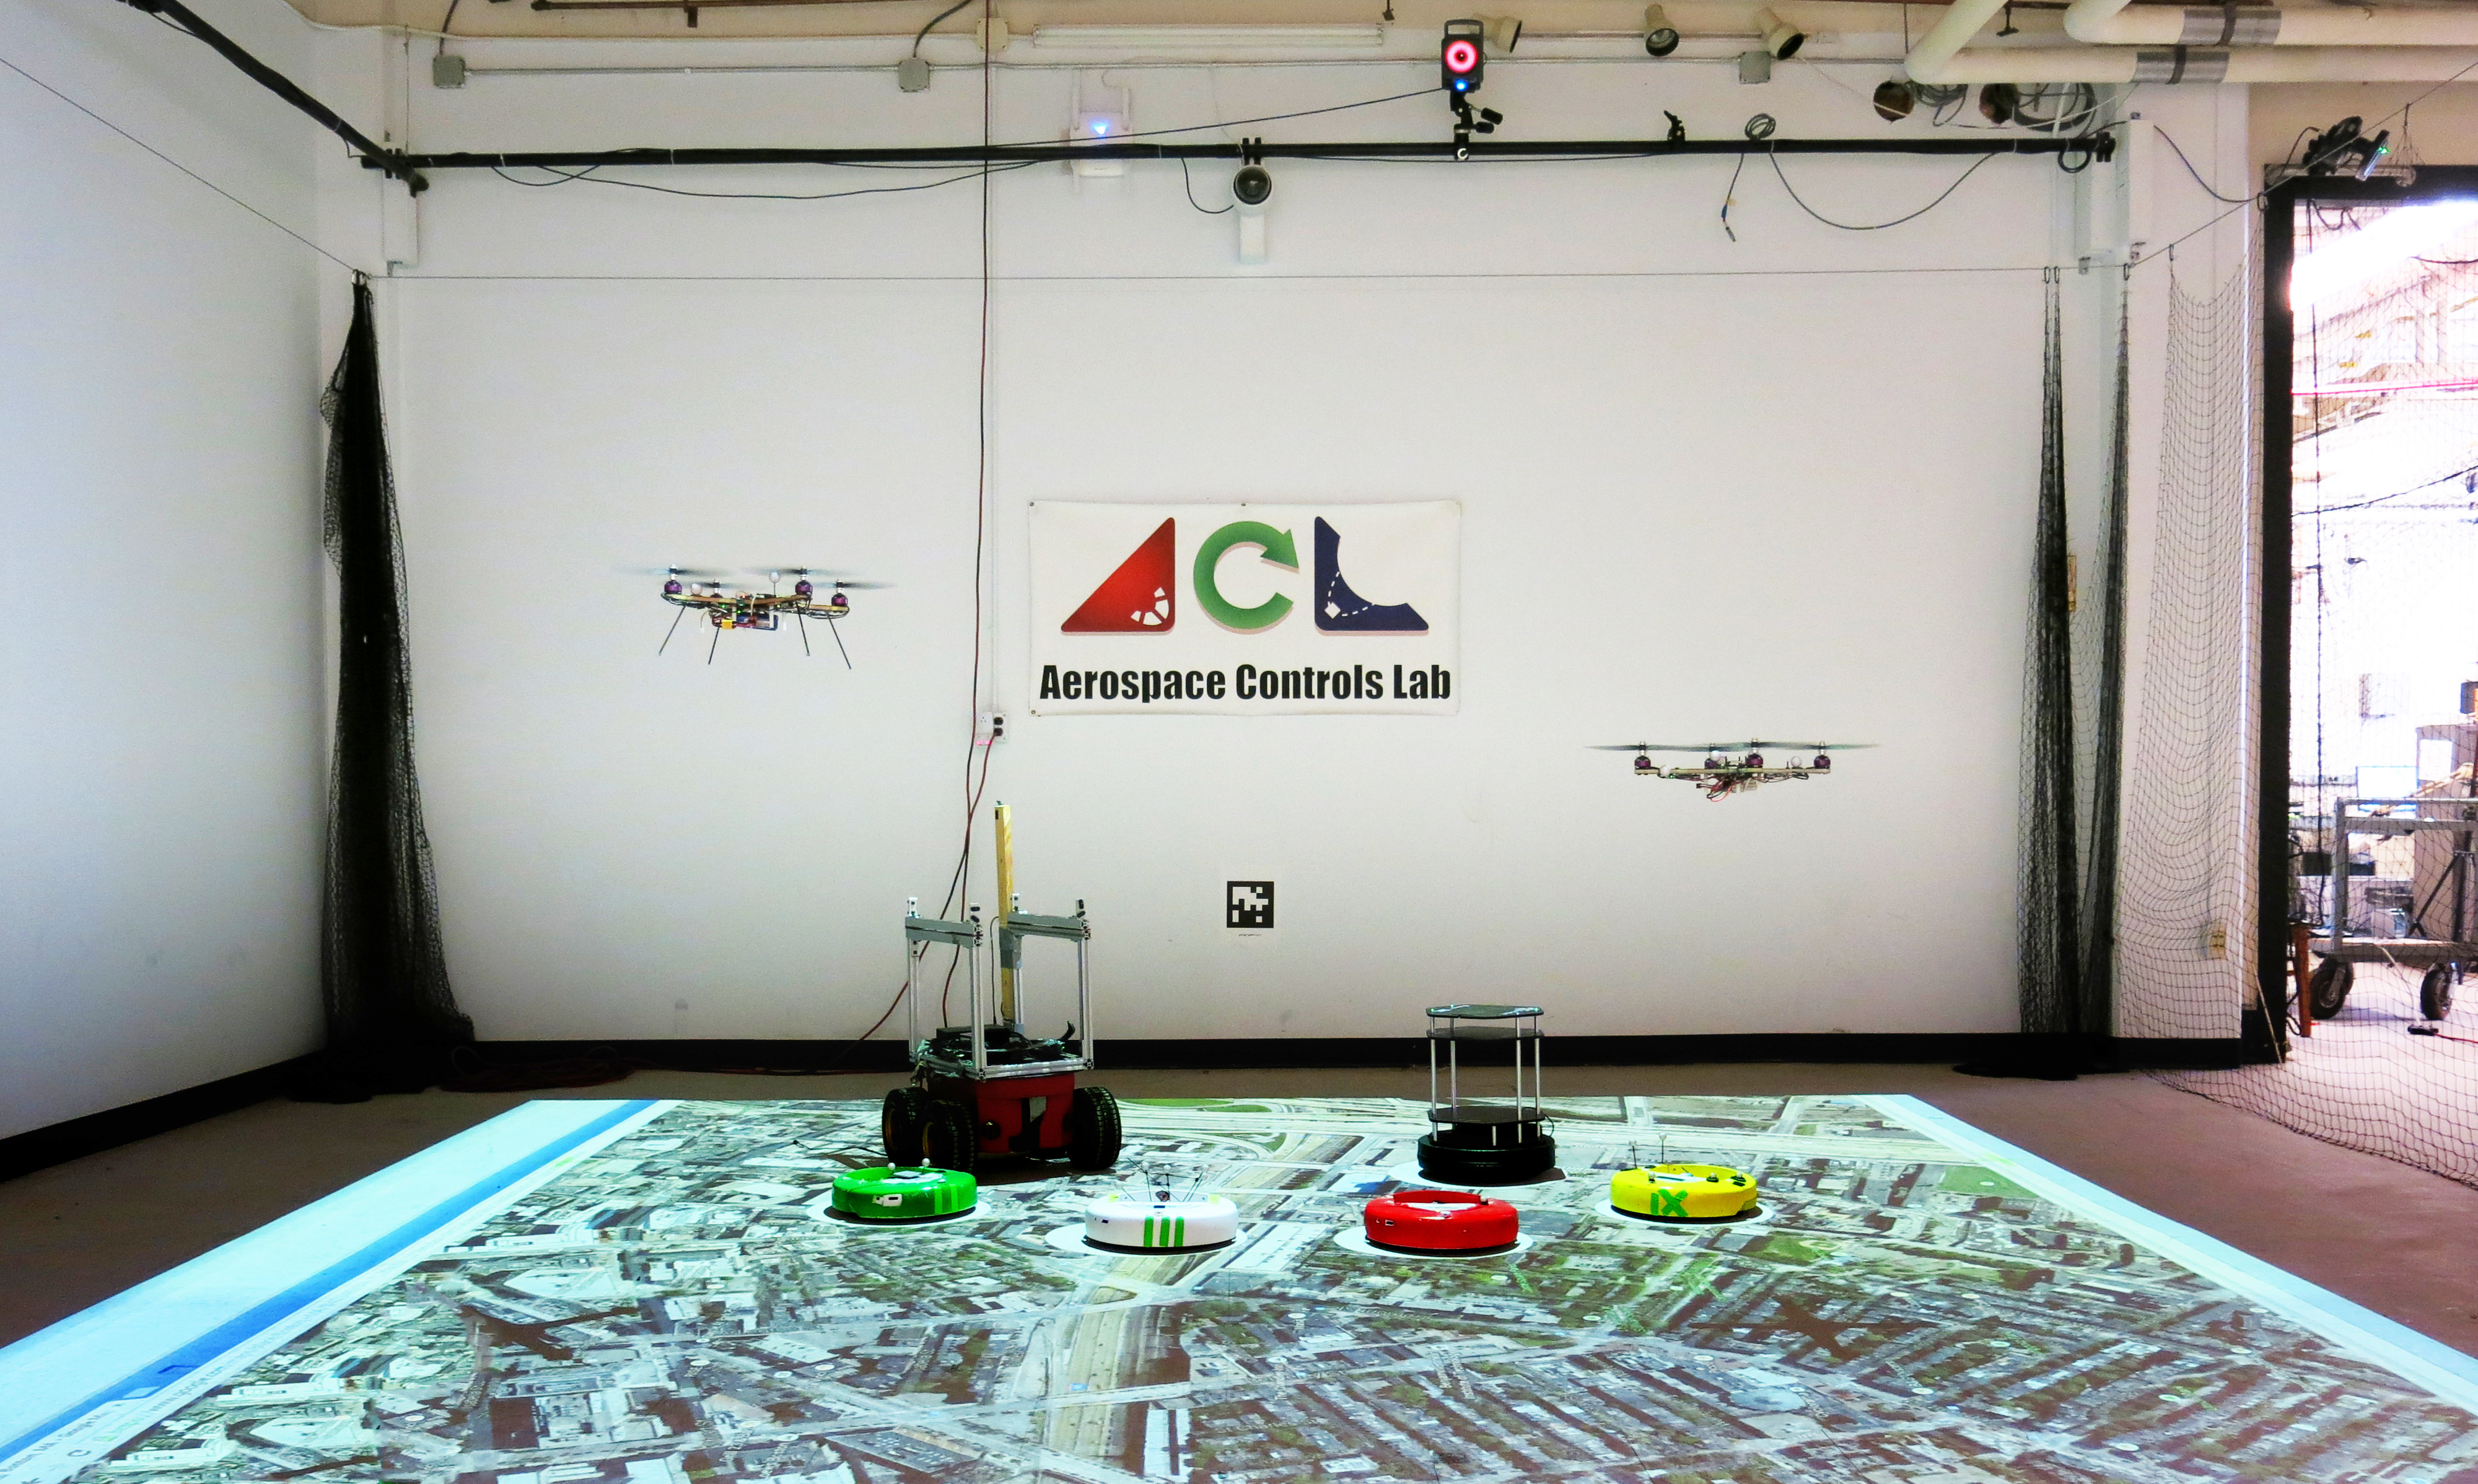 | Measurable Augmented Reality for Prototyping Cyber-Physical Systems (MAR-CPS)
Shayegan Omidshafiei, Ali-akbar Ahga-mohammadi, Steven Chen, N. Kemal Ure, 2014
We propose a platform designed to transform indoor laboratories into controlled simulations of outdoor environments. | |