yixuany [at] mit [dot] edu 31-234B
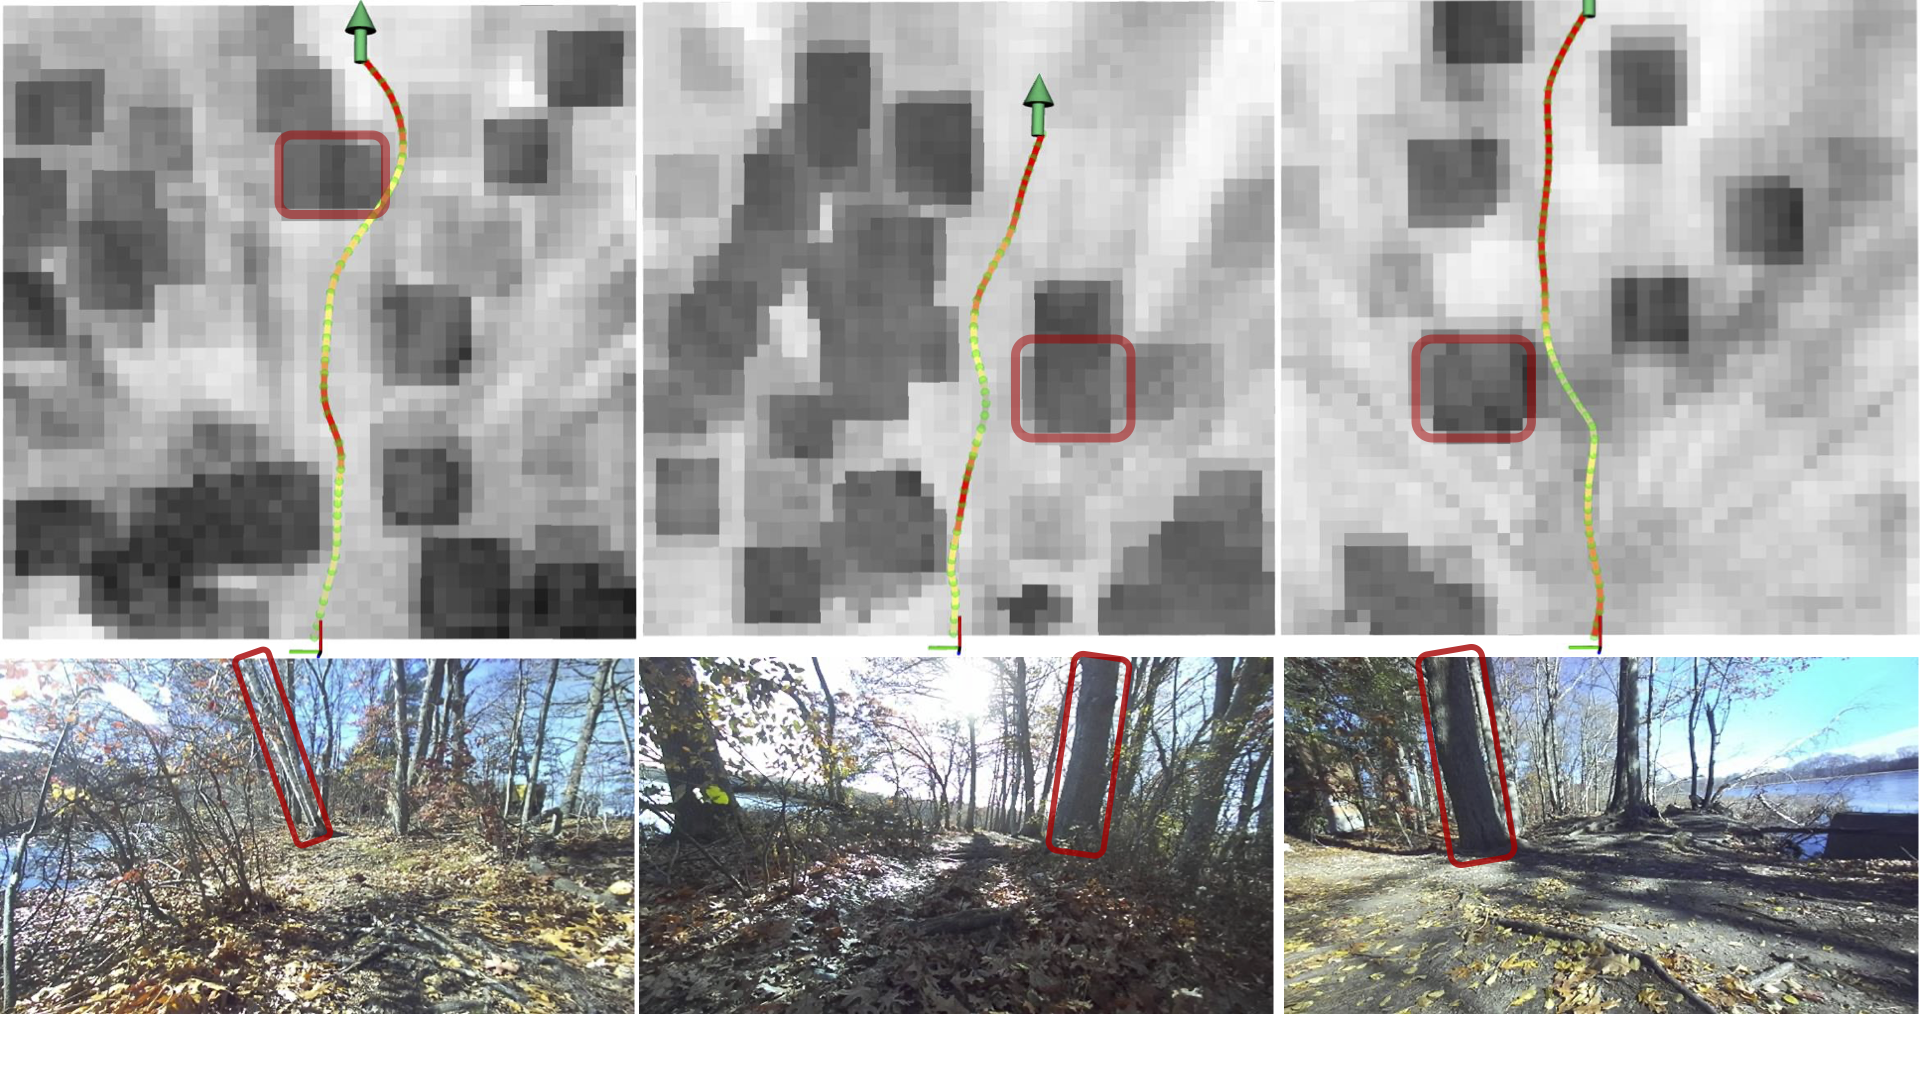
Off-Road Navigation via Implicit Neural Representation of Terrain Traversability Yixuan (Lucas) Jia, Andy Li, 2026
Leverage implicit representation for gradient-based trajectory optimization that modulates path geometry and speed profile simultaneously.
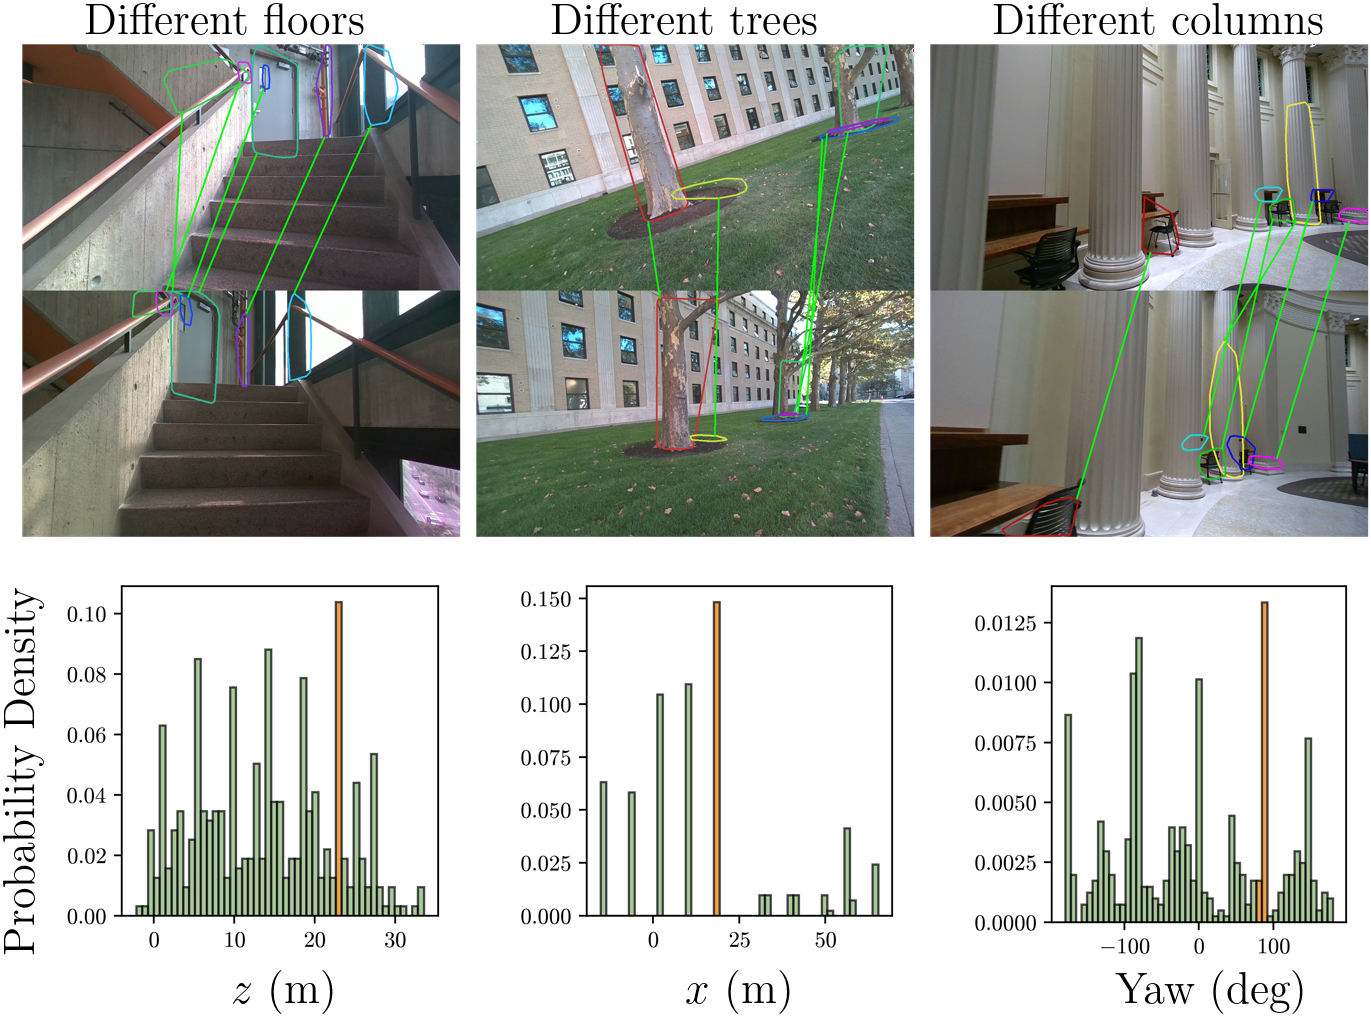
Distribution Estimation for Global Data Association via Approximate Bayesian Inference Yixuan (Lucas) Jia, Mason Peterson, Andy Li, 2026
Leverage approximate Bayesian inference to estimate the distribution of potential loop closures.
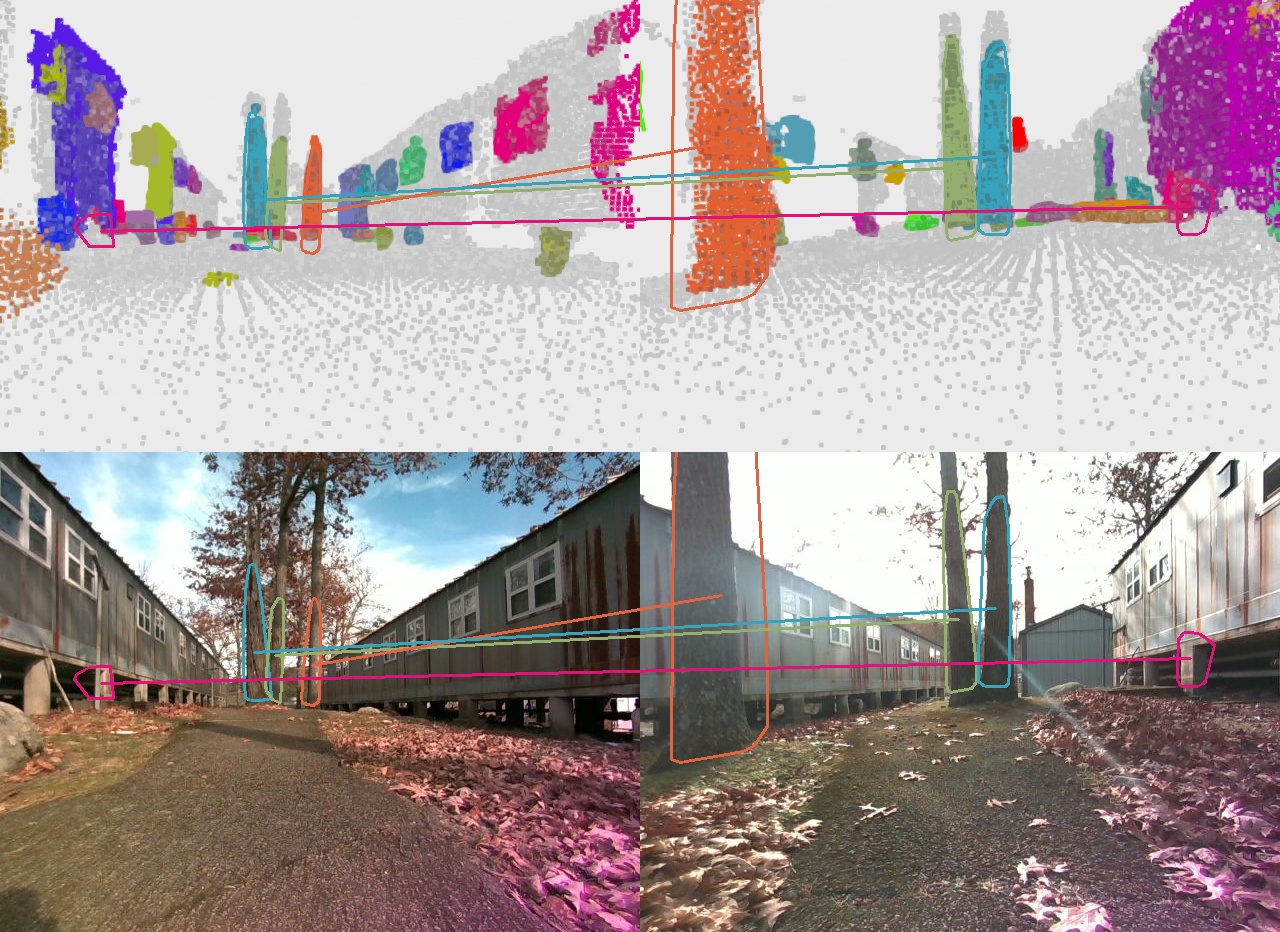
Open-Set Object Mapping and Loop Closures Mason Peterson, Yulun Tian, Yixuan (Lucas) Jia, 2025
This project presents an outdoor global localization method based on robust registration of open-set segment maps.