| Ali-akbar Ahga-mohammadi
Alum aliagha [at] mit [dot] edu
32-D569 | | - Ph.D. in Computer Engineering, Texas A&M University, 2013
- M.S. in Electrical Engineering (Control Systems), K.N. Toosi OofTech, 2008
- B.S. in Electrical Engineering (Control Systems), Tabriz University, 2005
| - Planning and Conrol Under Uncertainty
- Decision Making and Stochastic Control in Information Space
- Robotics and CyberPhysical Systems
- Estimation and Filtering Theory
| 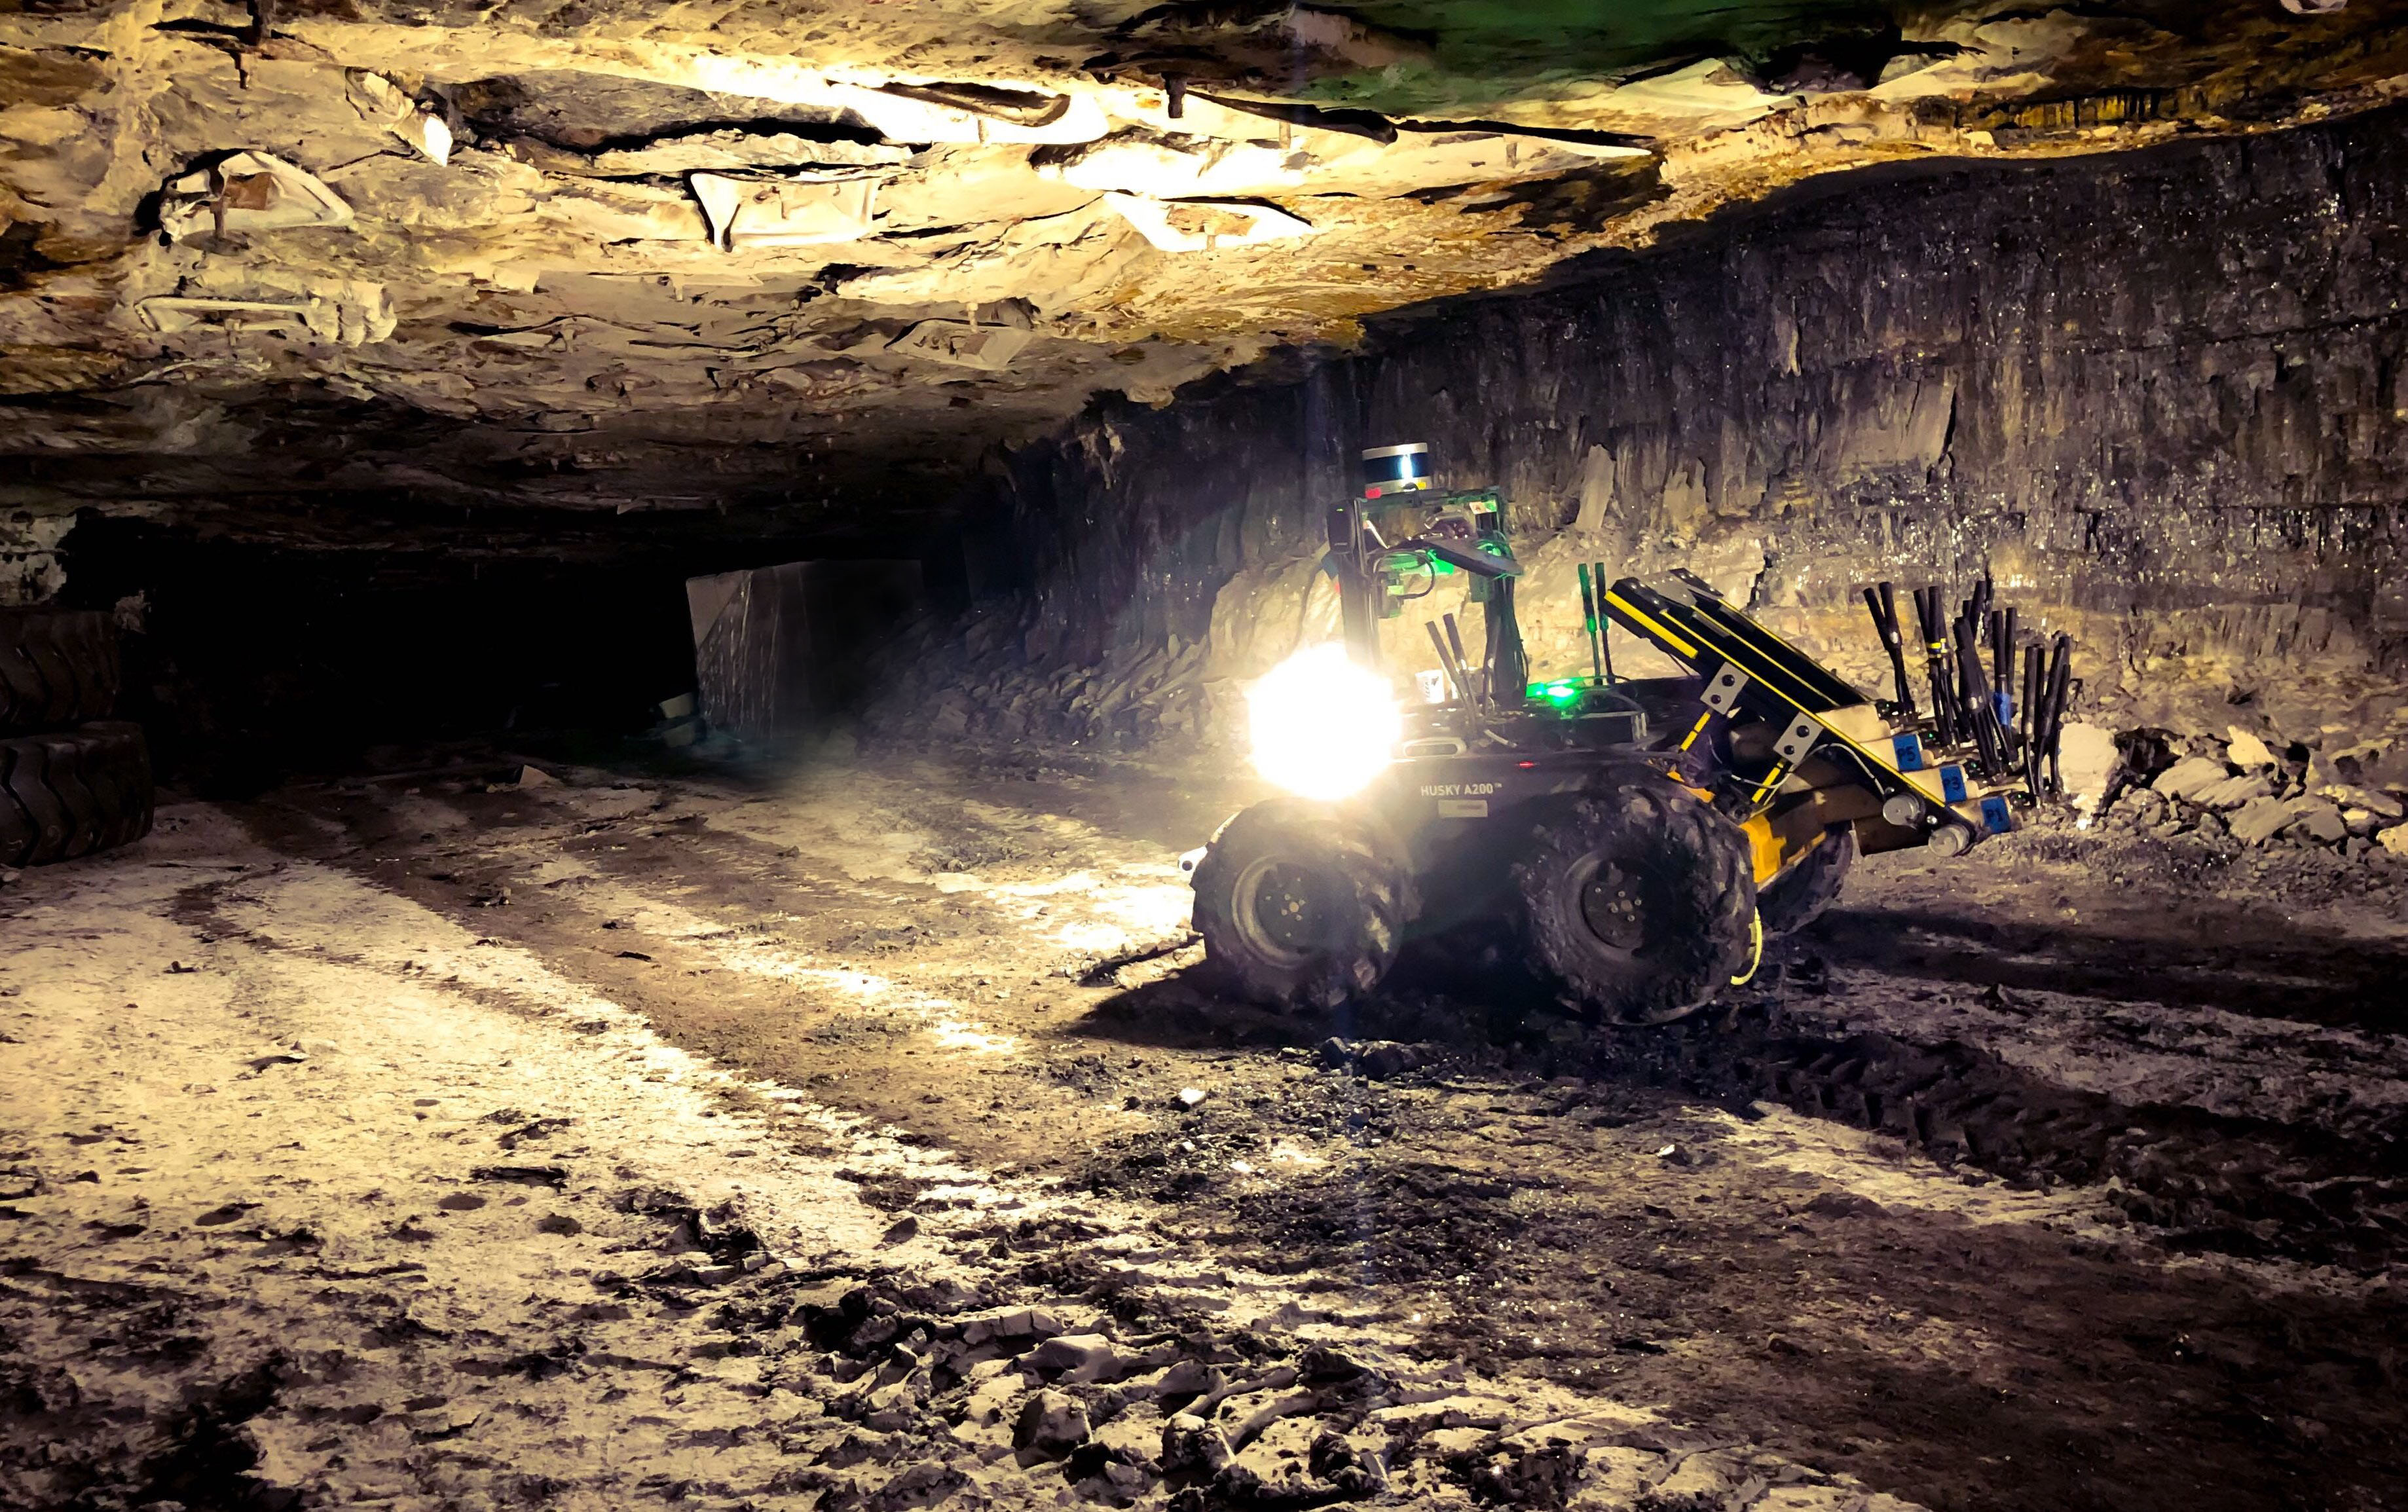 | Lidar-Inertial Observability-Aware Navigator
Andrea Tagliabue, Jesus Tordesillas Torres, Xiaoyi (Jeremy) Cai, Ali-akbar Ahga-mohammadi, 2020
This work presents the Lidar-Inertial Observability-Aware Navigator used at the DARPA Subt. challenge. | 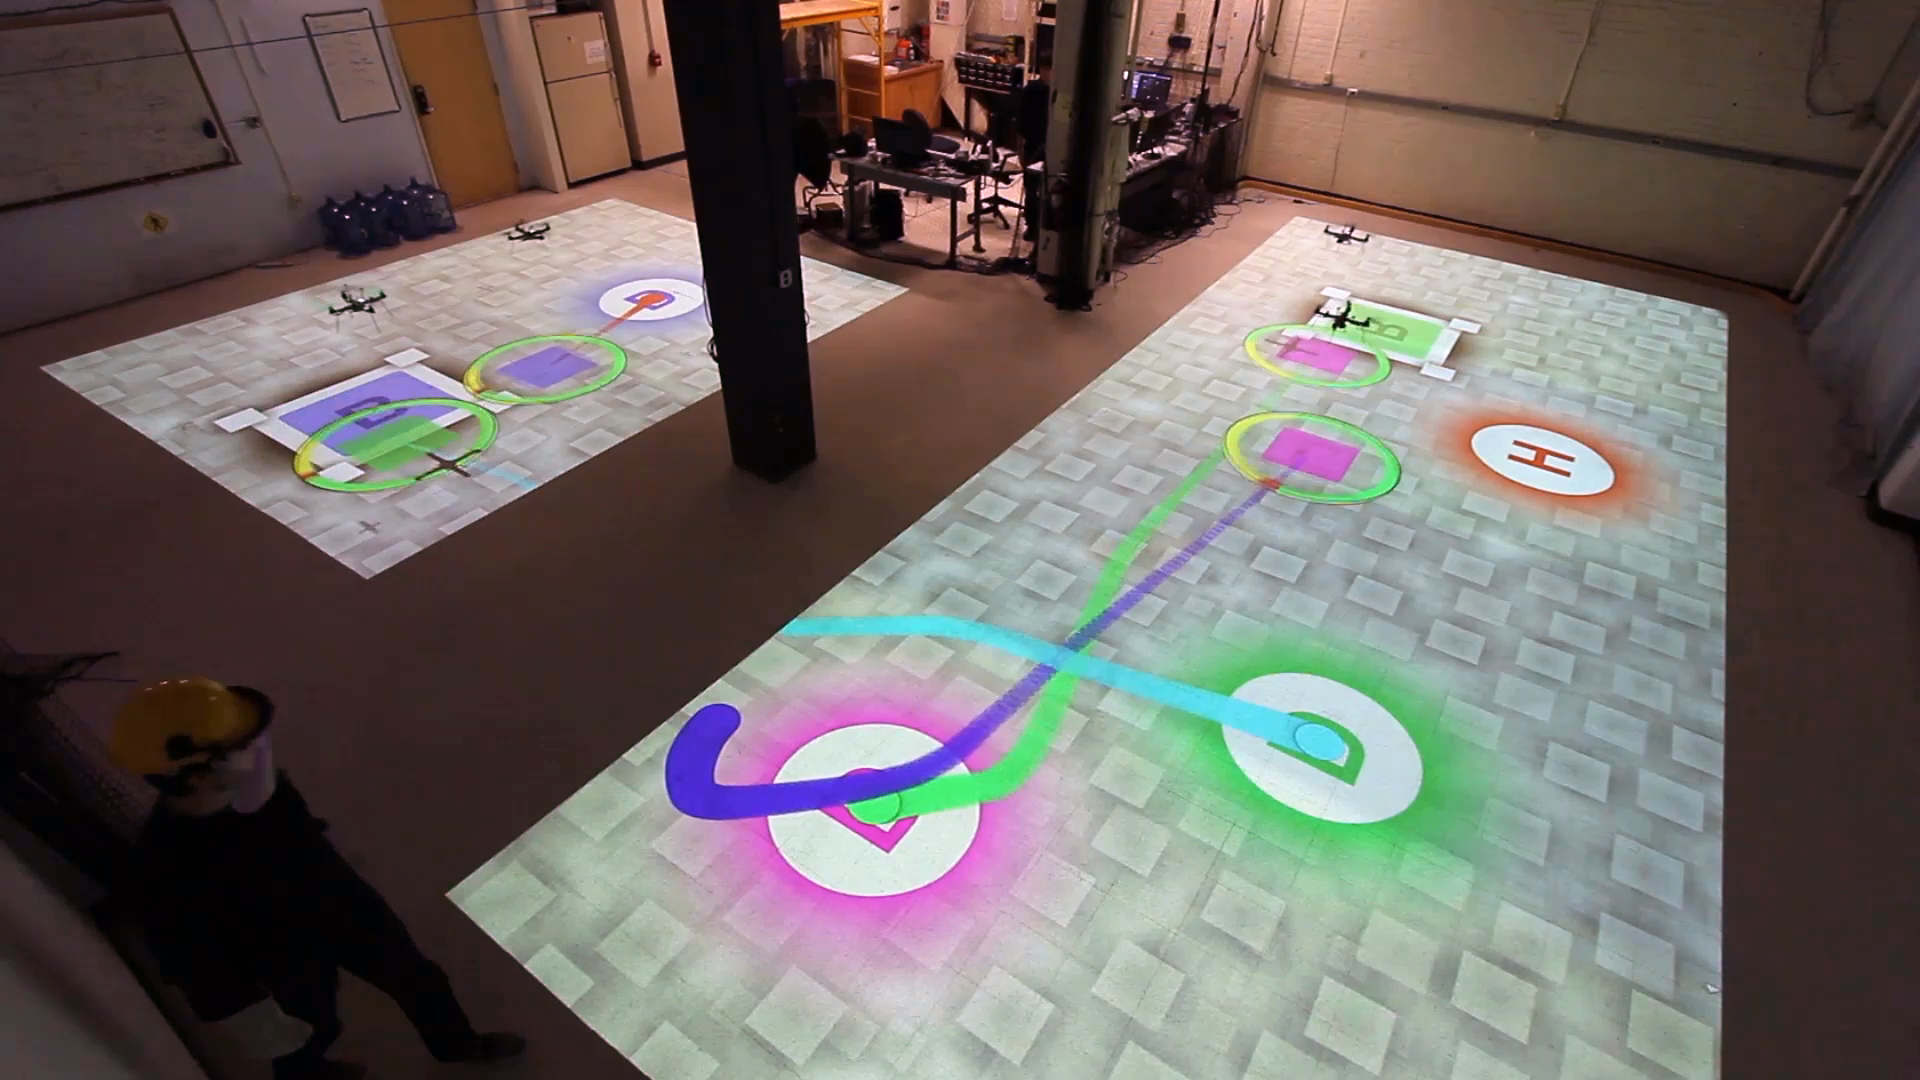 | Decentralized Control of Multi-Robot Partially Observable Markov Decision Processes using Belief Space Macro-actions
Shayegan Omidshafiei, Ali-akbar Ahga-mohammadi, Christopher Amato, Shih-Yuan Liu, Miao Liu, 2014
This work extends the Dec-POMDP model to the Decentralized Partially Observable Semi-Markov Decision Process (Dec-POSMDP) to take advantage of high-level representations that are natural for multi-robot problems and to facilitate scalable solutions to large discrete and continuous problems. | 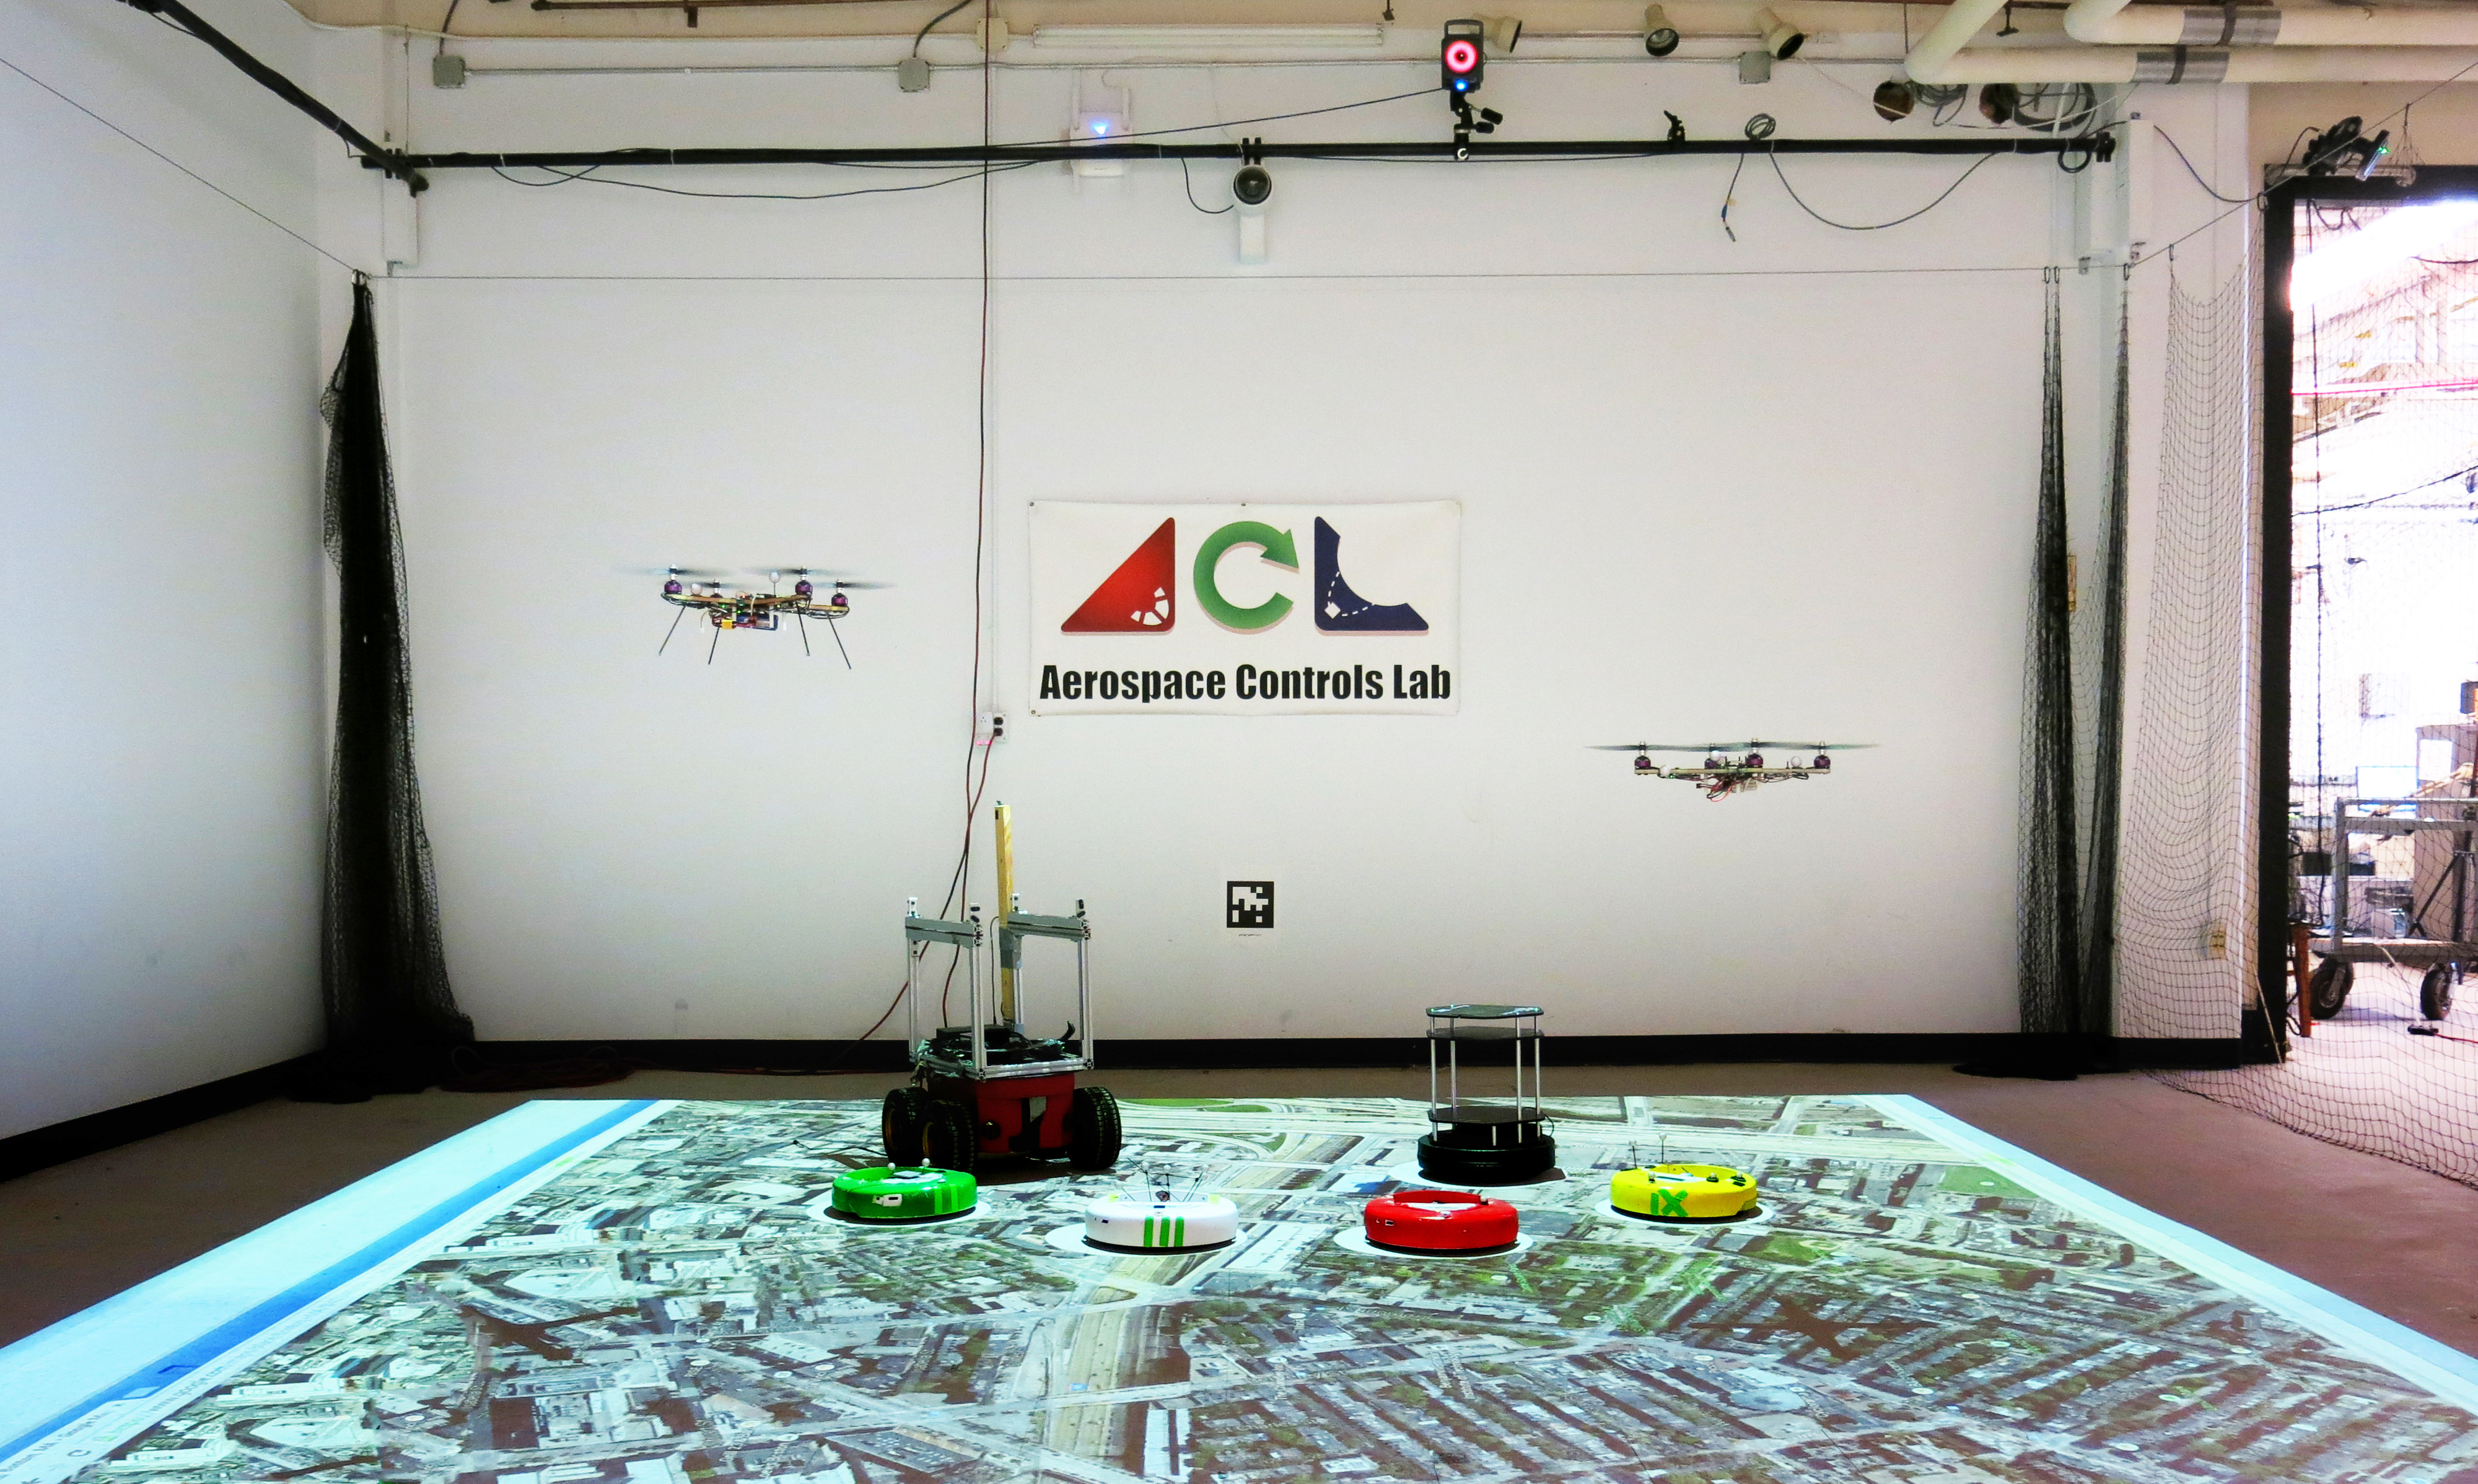 | Measurable Augmented Reality for Prototyping Cyber-Physical Systems (MAR-CPS)
Shayegan Omidshafiei, Ali-akbar Ahga-mohammadi, Steven Chen, N. Kemal Ure, 2014
We propose a platform designed to transform indoor laboratories into controlled simulations of outdoor environments. | |