 | Predictive Motion Modeling
Steven Chen, Justin Miller, Miao Liu, Shih-Yuan Liu, 2015
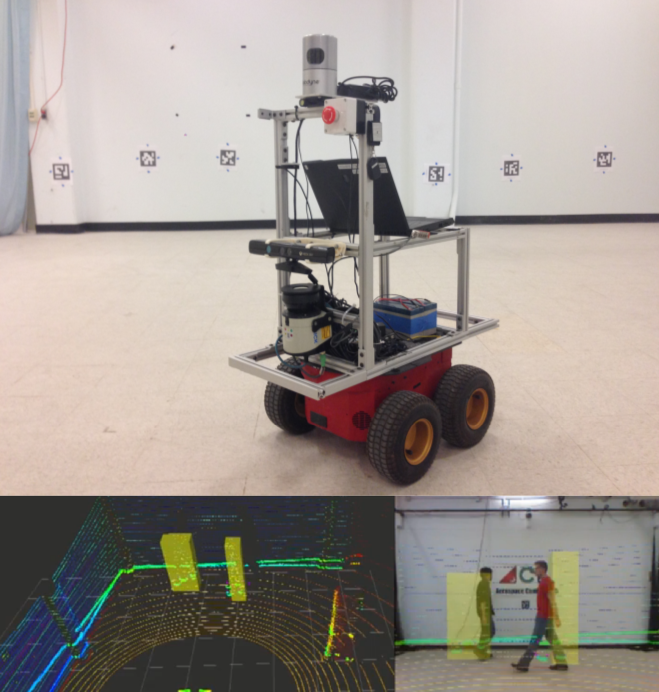
This work develops an algorithm that combines the strengths of the Markovian-based and clustering-based methods, by finding the local clusters characterized by partial trajectory segments, and making predictions using both the local motion models and the global Markovian transition dynamics. |
 | Decentralized Control of Multi-Robot Partially Observable Markov Decision Processes using Belief Space Macro-actions
Shayegan Omidshafiei, Ali-akbar Ahga-mohammadi, Christopher Amato, Shih-Yuan Liu, Miao Liu, 2014
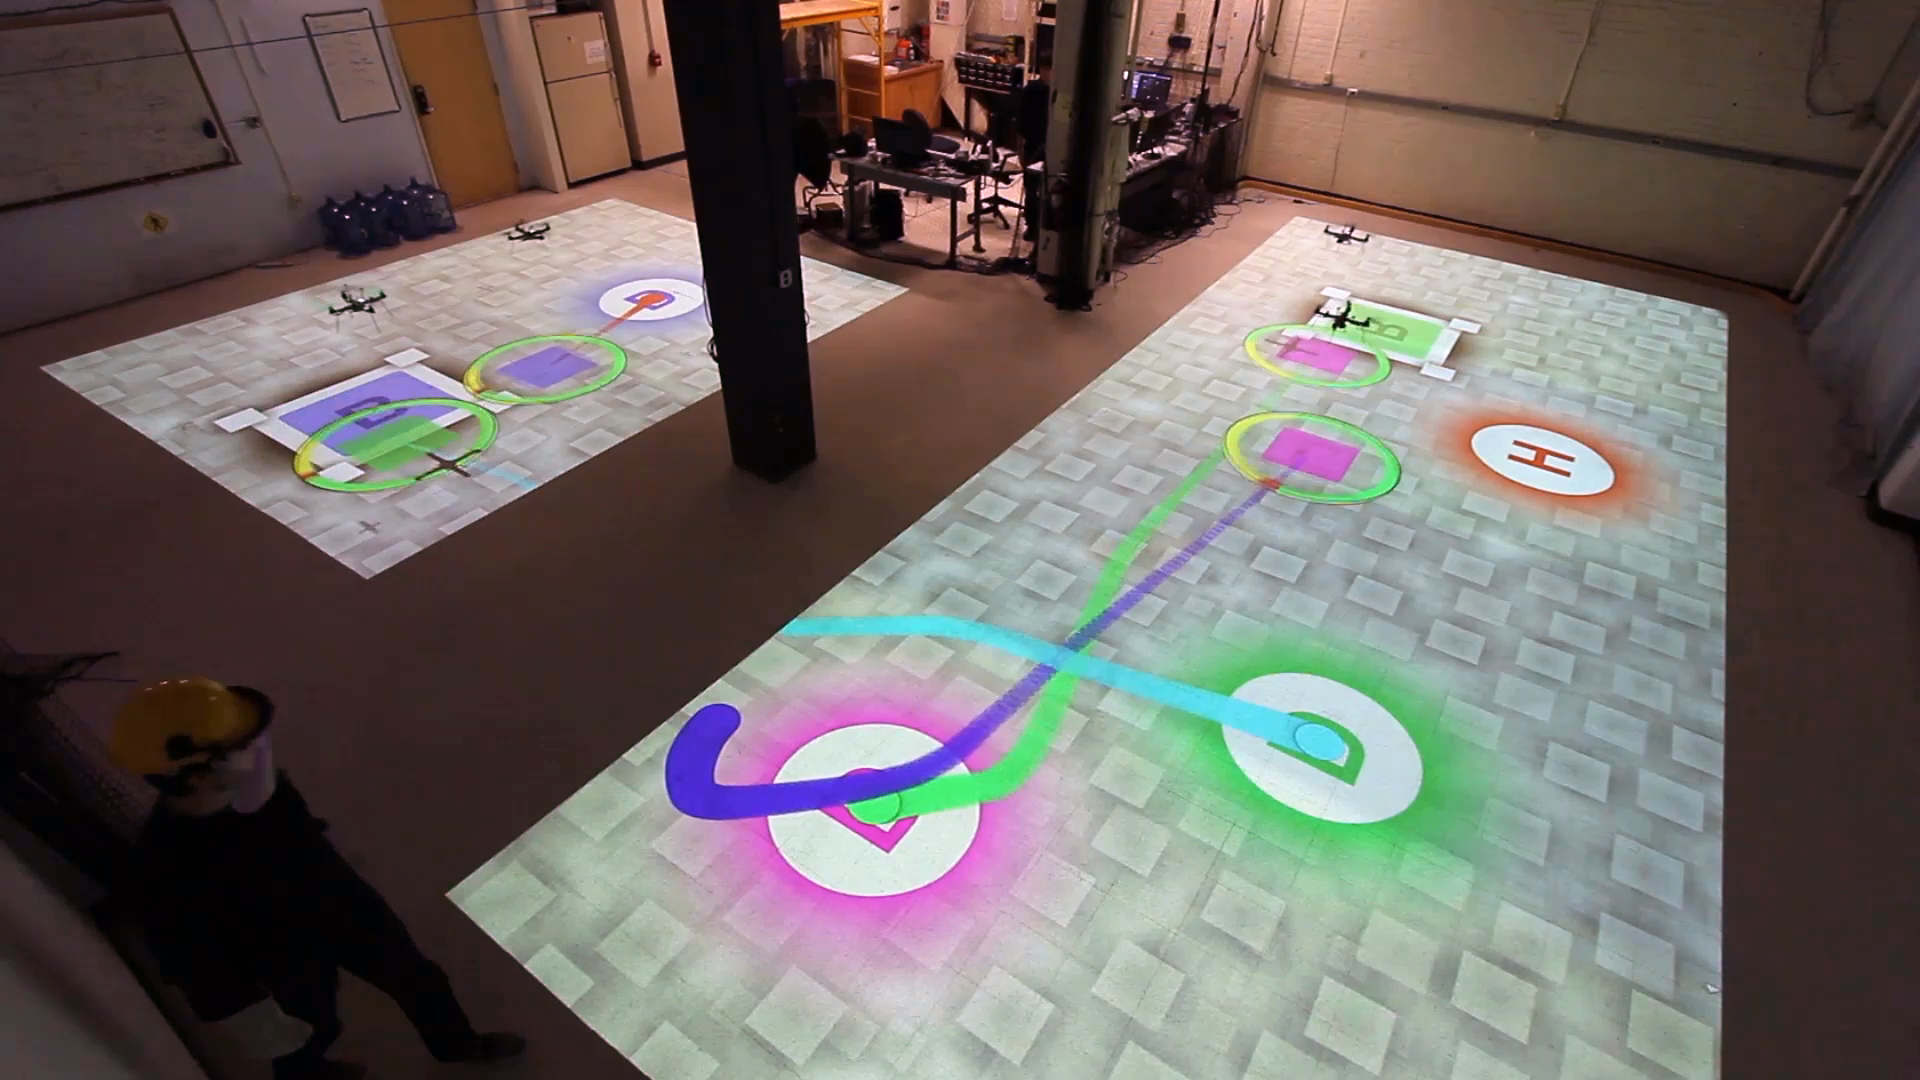
This work extends the Dec-POMDP model to the Decentralized Partially Observable Semi-Markov Decision Process (Dec-POSMDP) to take advantage of high-level representations that are natural for multi-robot problems and to facilitate scalable solutions to large discrete and continuous problems. |