| Michael Everett
Alum GitHub / Website
mfe [at] mit [dot] edu
31-235C | | - Ph.D. in Mechanical Engineering, MIT, 2020
- S.M. in Mechanical Engineering, MIT, 2017
- S.B. in Mechanical Engineering, MIT, 2015
| - Robust Learning
- Collision Avoidance
- Motion Planning
|  | Evidential Traversability Learning
Xiaoyi (Jeremy) Cai, Lakshay Sharma, Michael Everett, 2024
Uncertainty-aware traversability learning and risk-aware navigation in off-road terrain |  | Risk-Aware Mapping and Planning
Lakshay Sharma, Michael Everett, Donggun Lee, Xiaoyi (Jeremy) Cai, 2023
RAMP: A Risk-Aware Mapping and Planning Pipeline for Fast Off-Road Ground Robot Navigation | 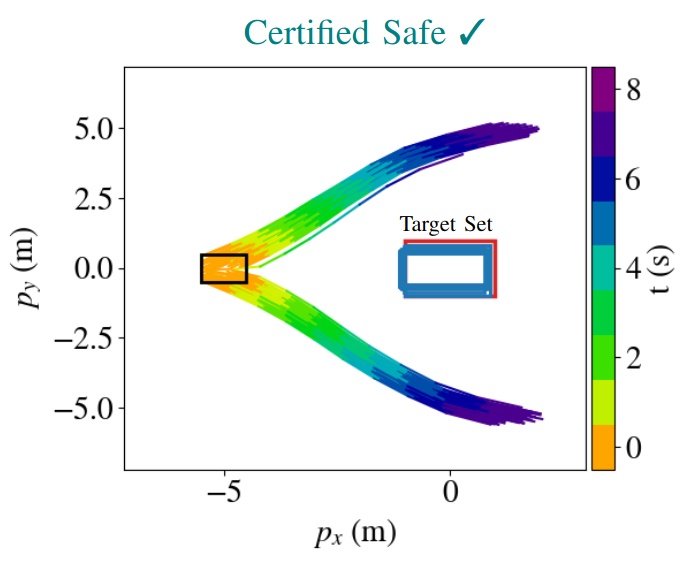 | Backward Reachability for Neural Feedback Loops
Nicholas Rober, Michael Everett, 2022
This project developed a backward reachability strategy to certify safety for systems controlled by neural networks | 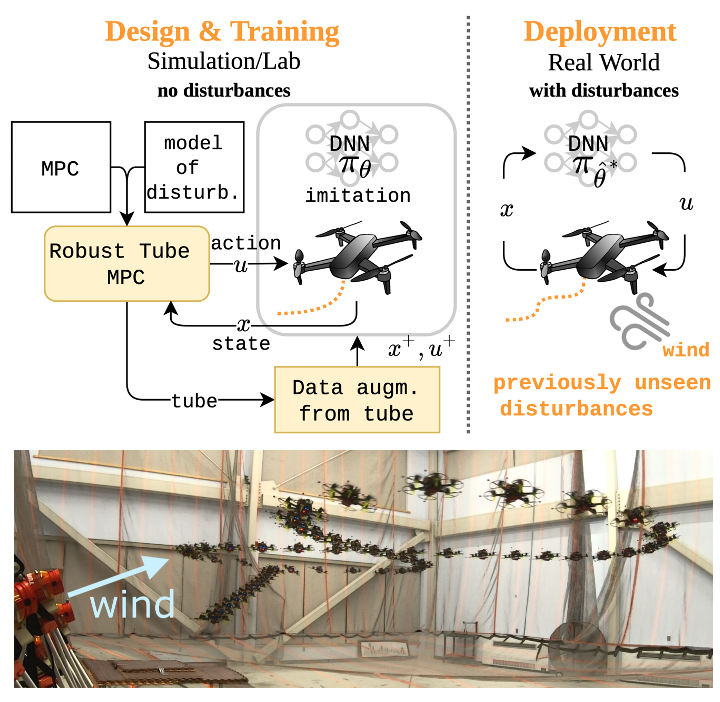 | Efficient Learning of Neural Network Policies via Imitation Learning and Tube MPC
Andrea Tagliabue, Dong-Ki Kim, Michael Everett, 2022
Use a Robust Tube variant of MPC to efficiently learn Neural Network policies via Imitation Learning. | 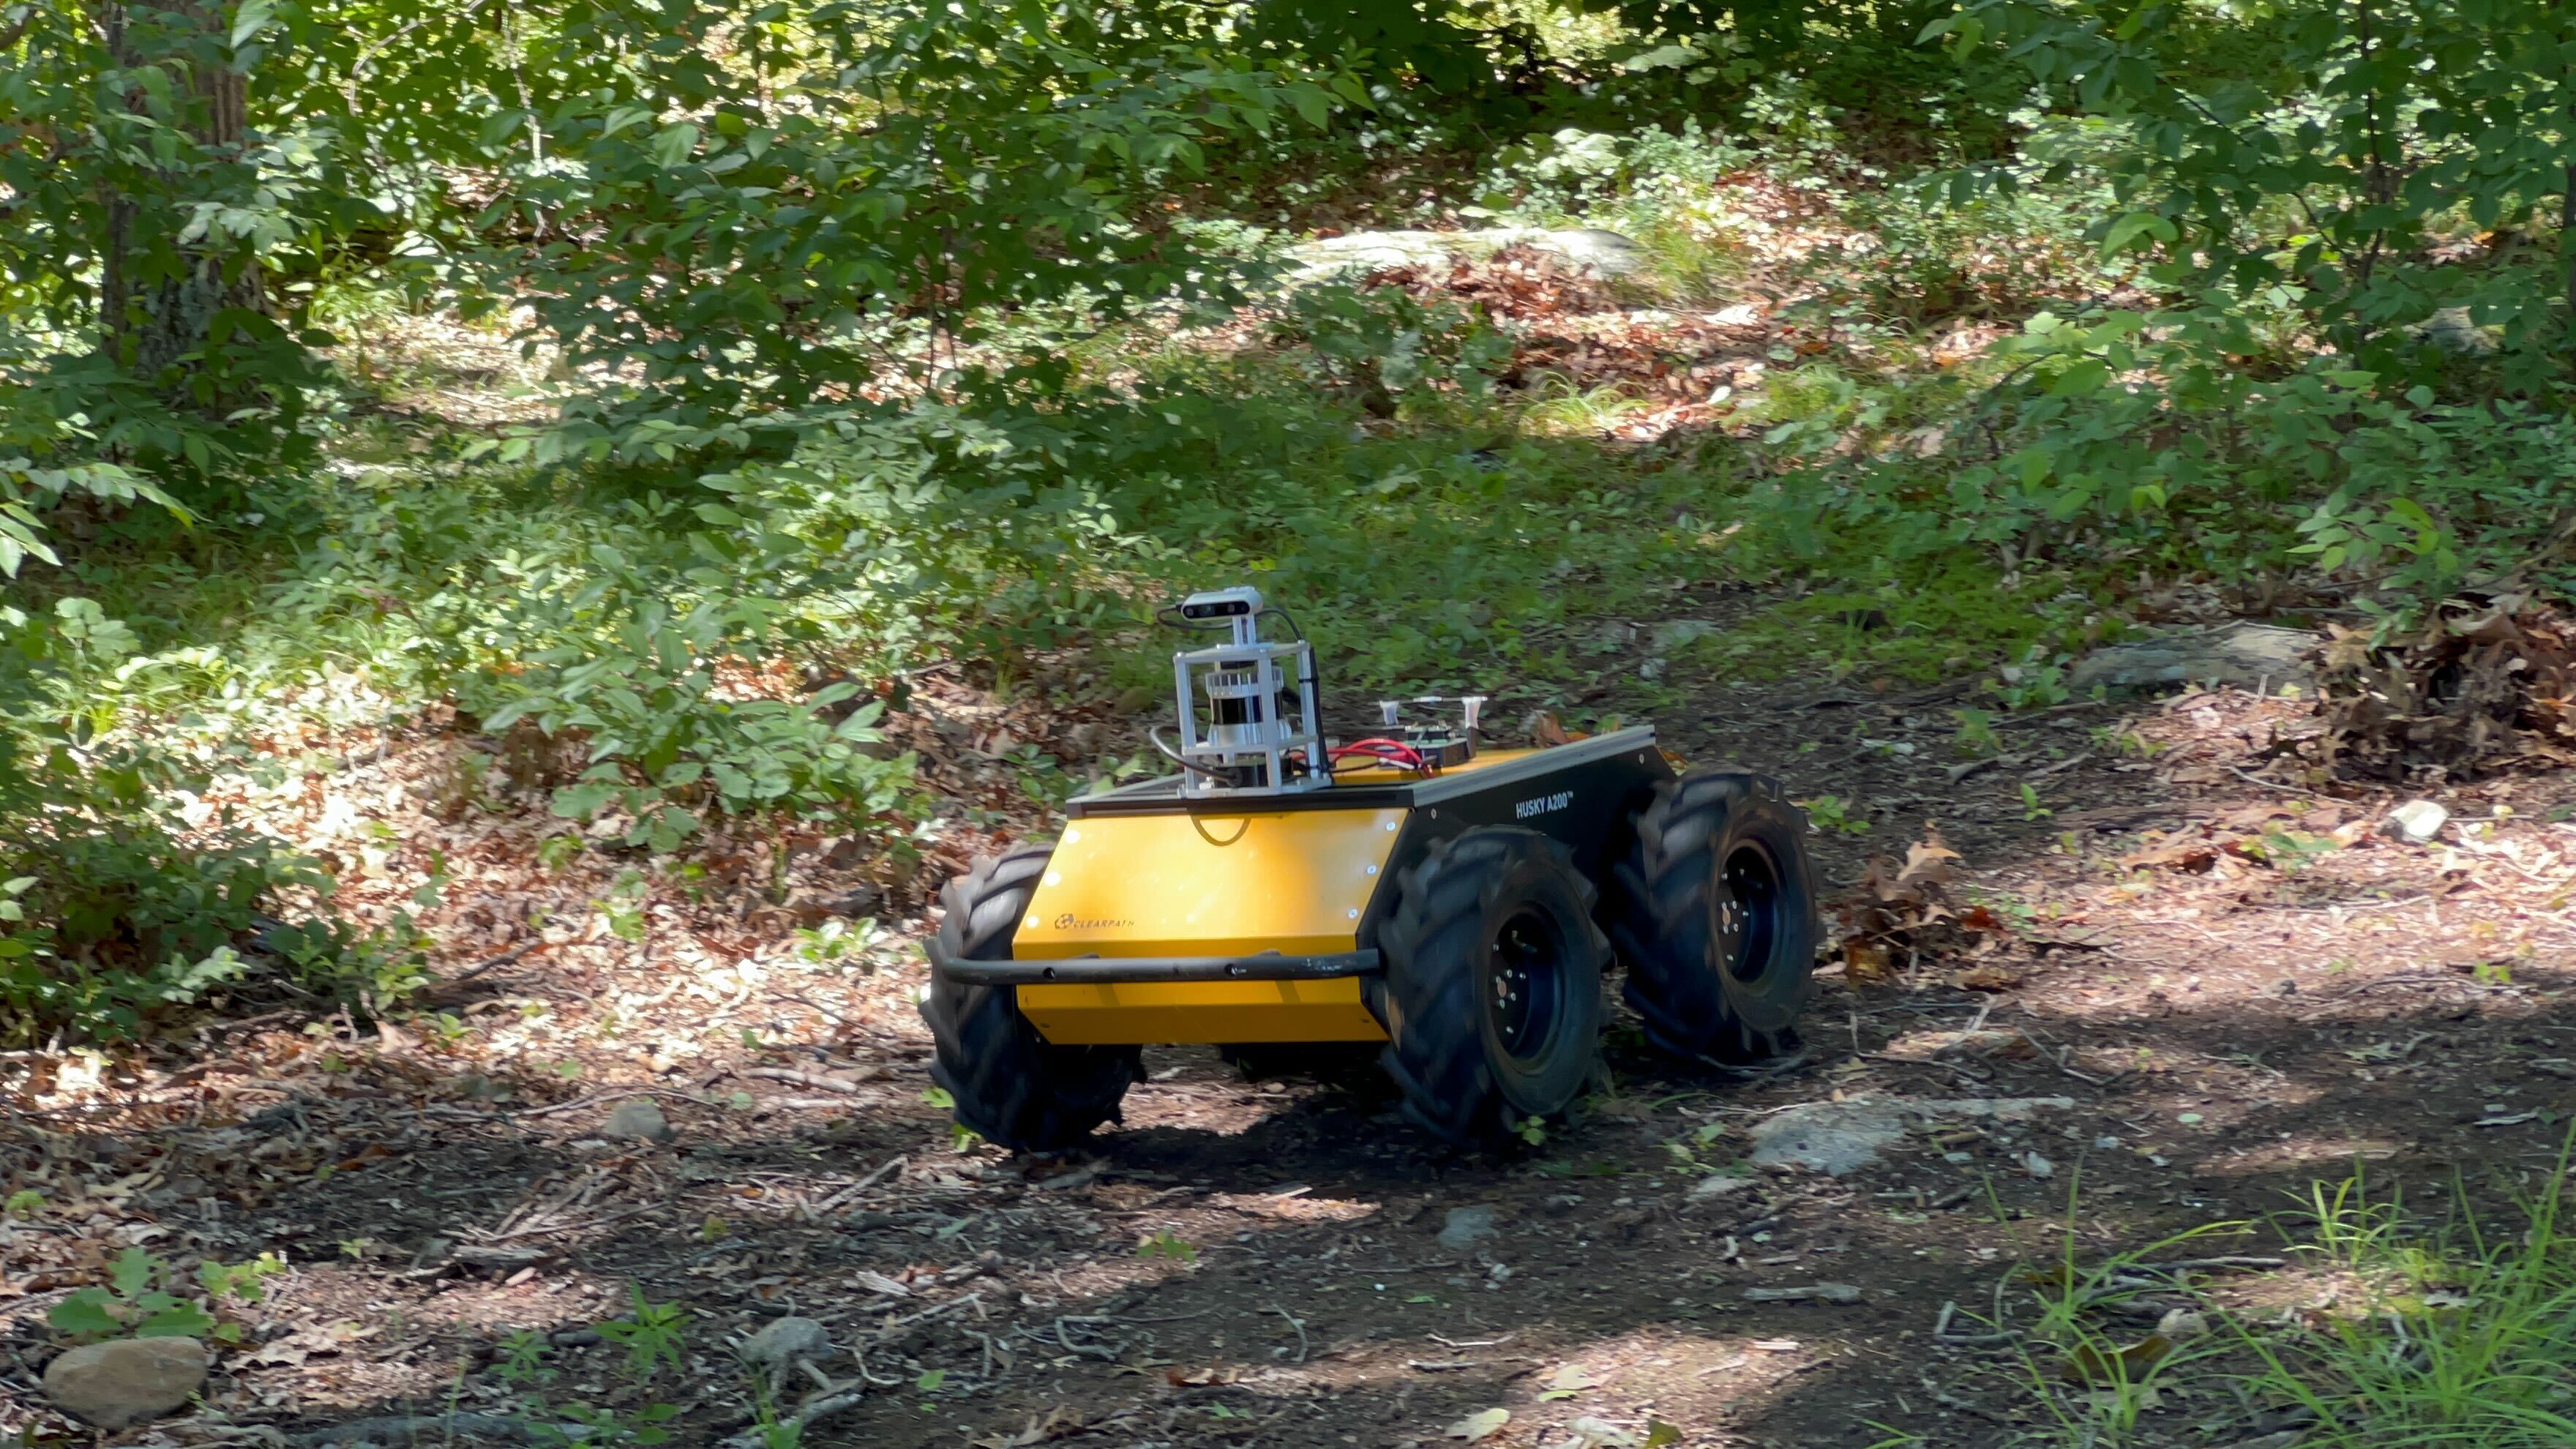 | Risk-Aware Off-Road Navigation Leveraging Semantics
Xiaoyi (Jeremy) Cai, Michael Everett, 2022
Use semantics of the environment to infer terrain traversability based on history of speed data. | 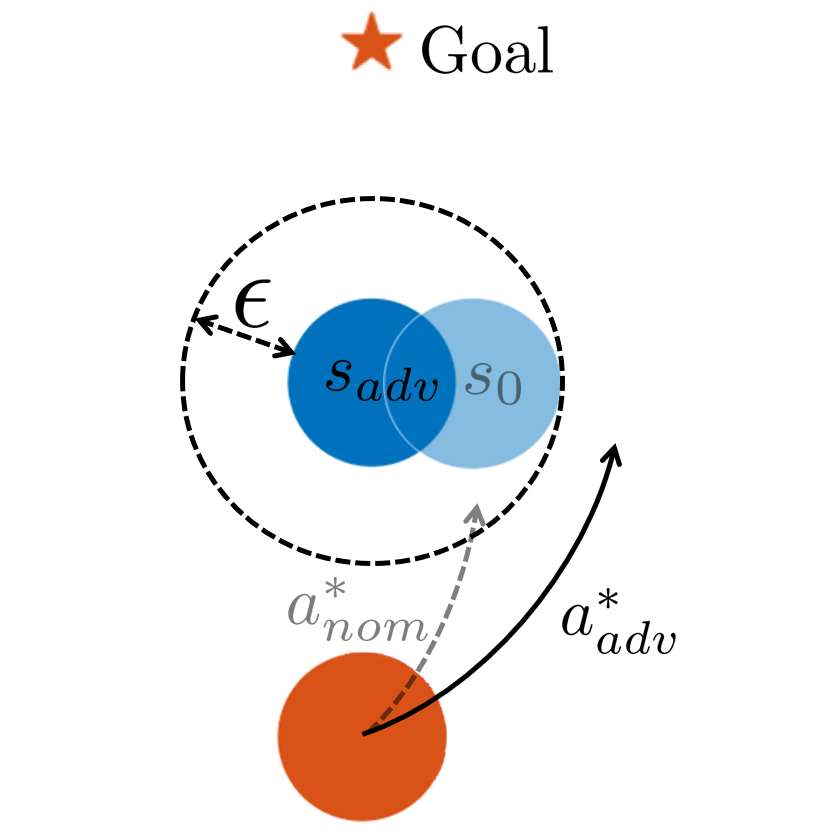 | Certified Adversarial Robustness for Deep RL
Michael Everett, Björn Lütjens, 2020
This project develops deep RL algorithms that are robust to an adversarial perturbation in the observation space |  | Self-Driving Delivery Robot
Michael Everett, Justin Miller (Ford), 2019
This project develops planning algorithms to enable autonomous navigation in the "last 100m" for delivery robots | 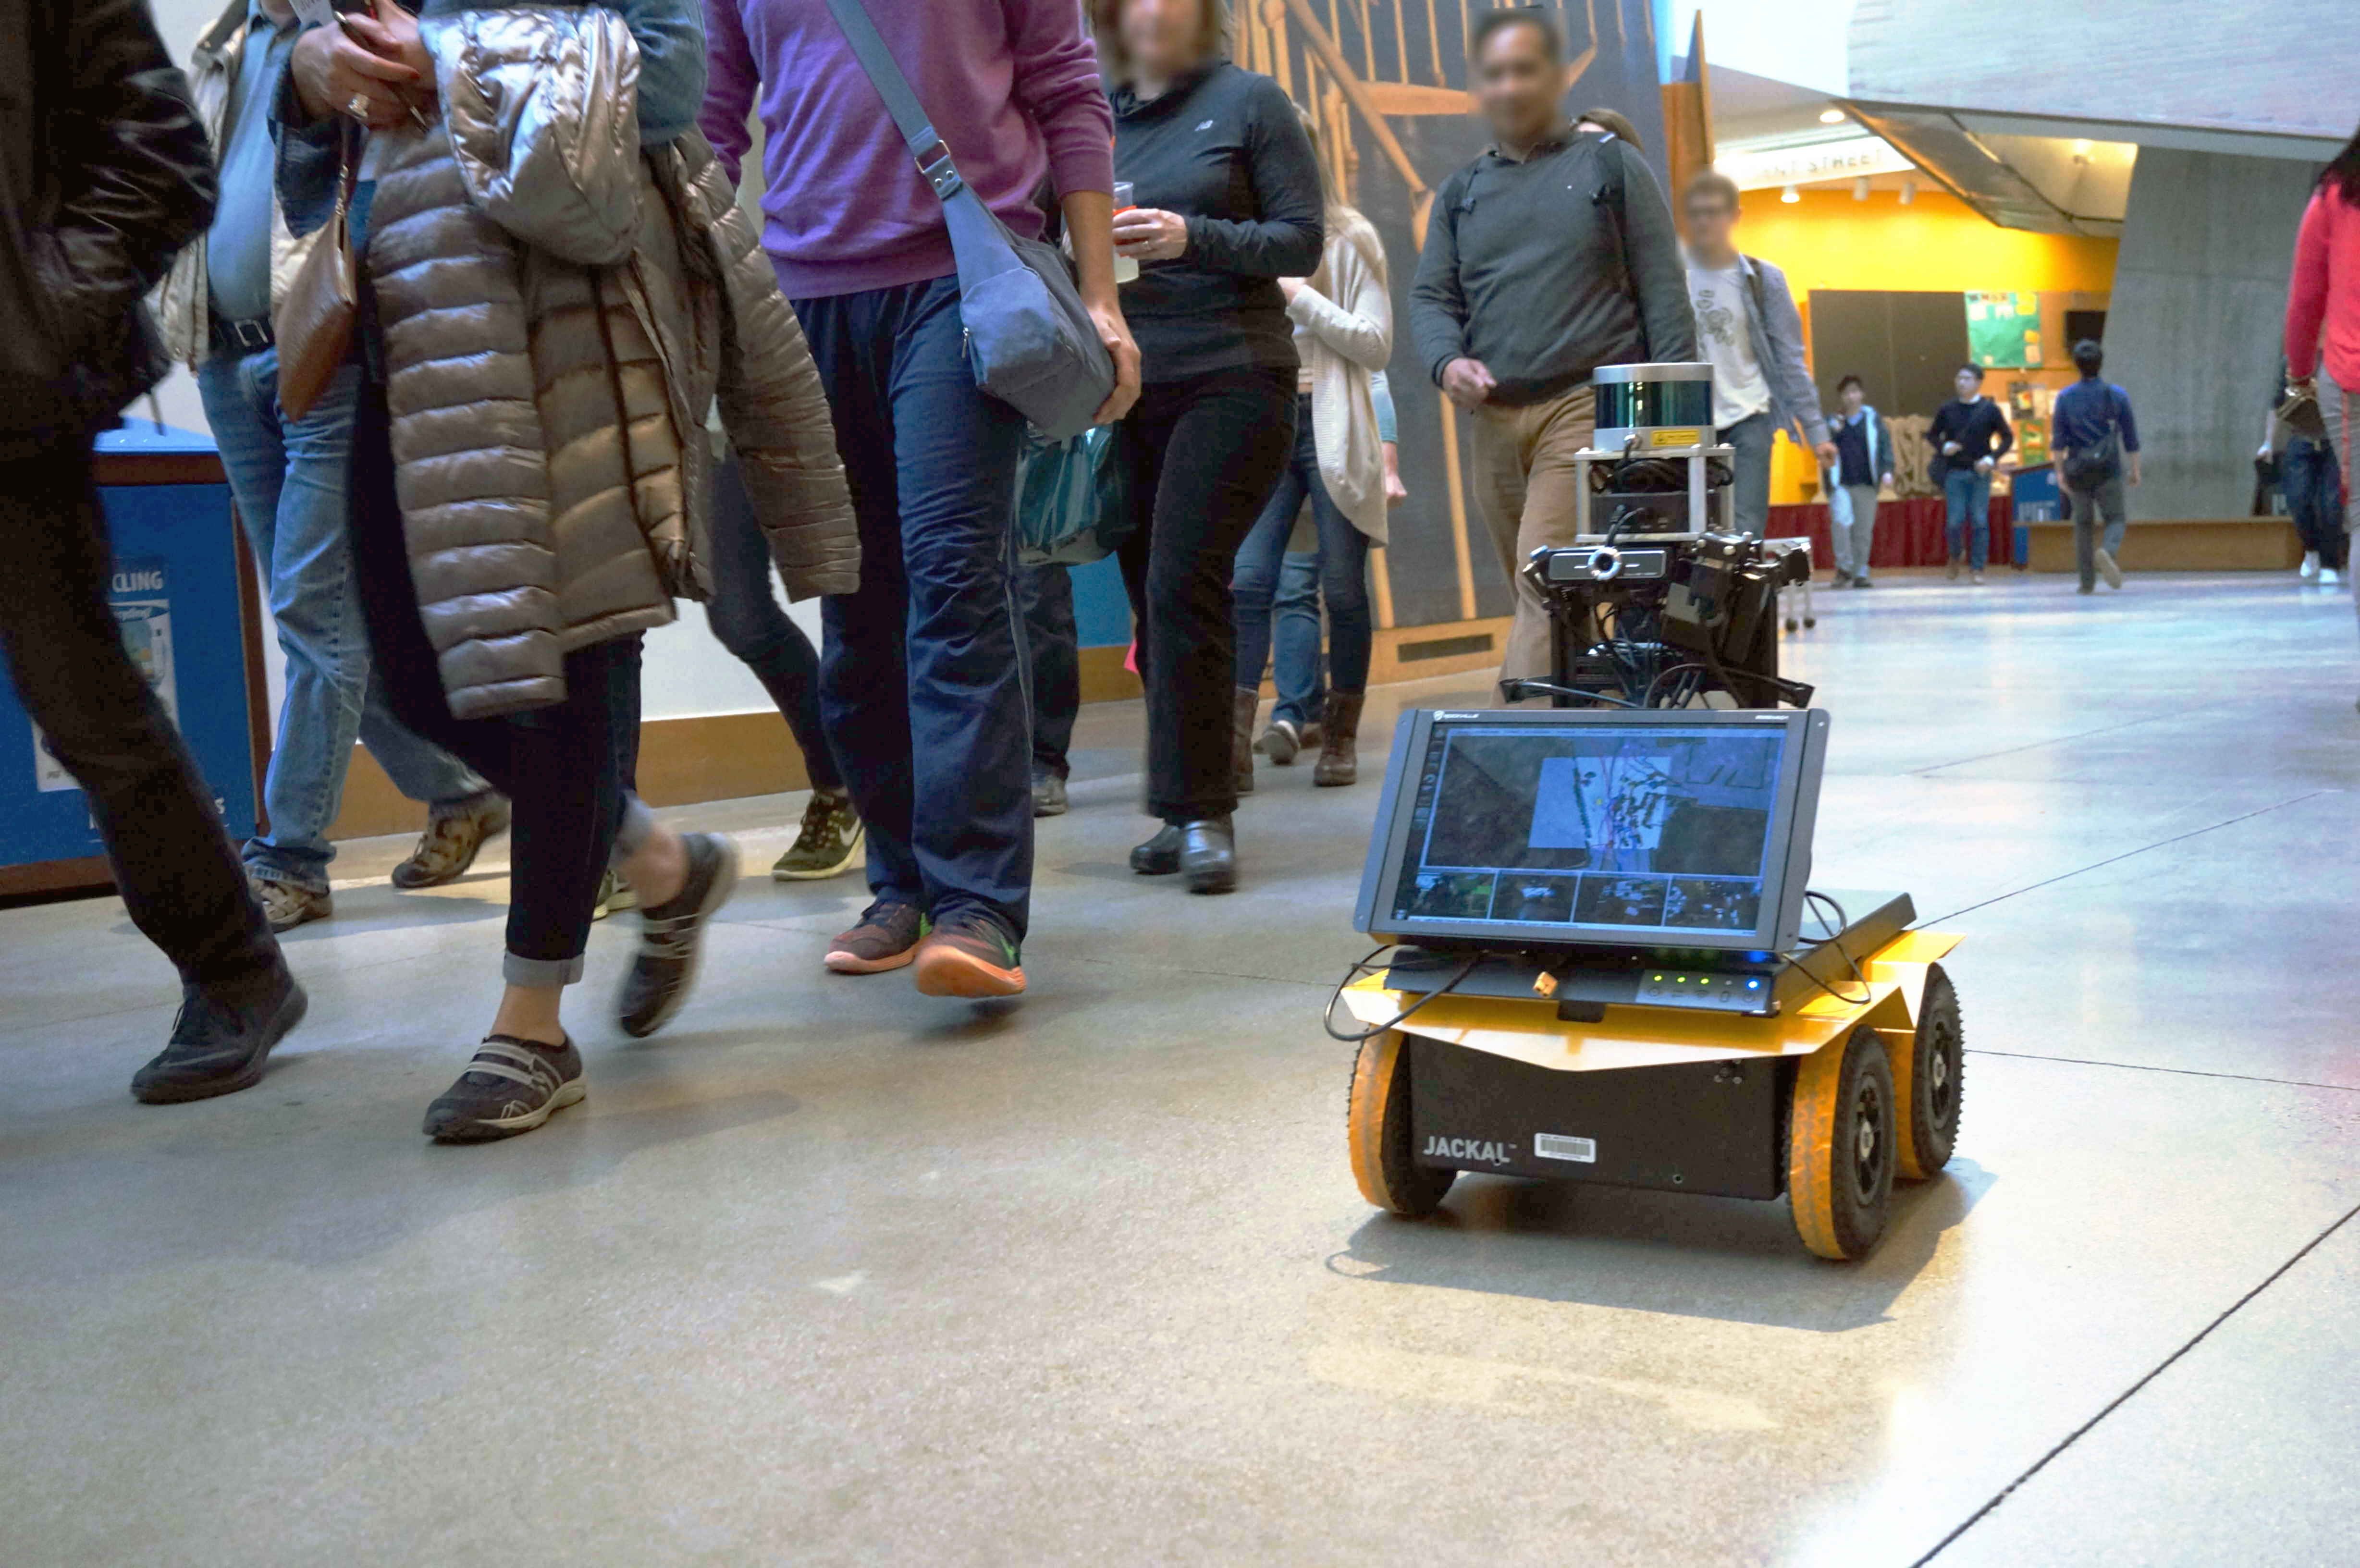 | Socially Acceptable Navigation
Michael Everett, Steven Chen, 2019
Collision avoidance algorithm using Deep RL. |  | Robust and Interpretable RL for Navigation in Pedestrian Crowds
Björn Lütjens, Michael Everett, 2018
Deep neural networks can fail overconfidently on novel observations. This work pioneers a reinforcement learning framework that reasons about the predictive confidence and is more robust to novel observations. | |