| Brett Lopez
Alum I am a graduate student studying control and planning for autonomous systems that have uncertain dynamics and experience uknown external disturbances. btlopez [at] mit [dot] edu
| | - Ph.D. in Aeronautics and Astronautics Engineering, MIT, 2019
- S.M. in Aeronautics and Astronautics Engineering, MIT, 2016
- S.B. in Aerospace Engineering, UCLA, 2014
| - Robust and Adaptive Nonlinear Control
- Model Predictive Control
- Collision Avoidance
- Robot Motion Planning
| 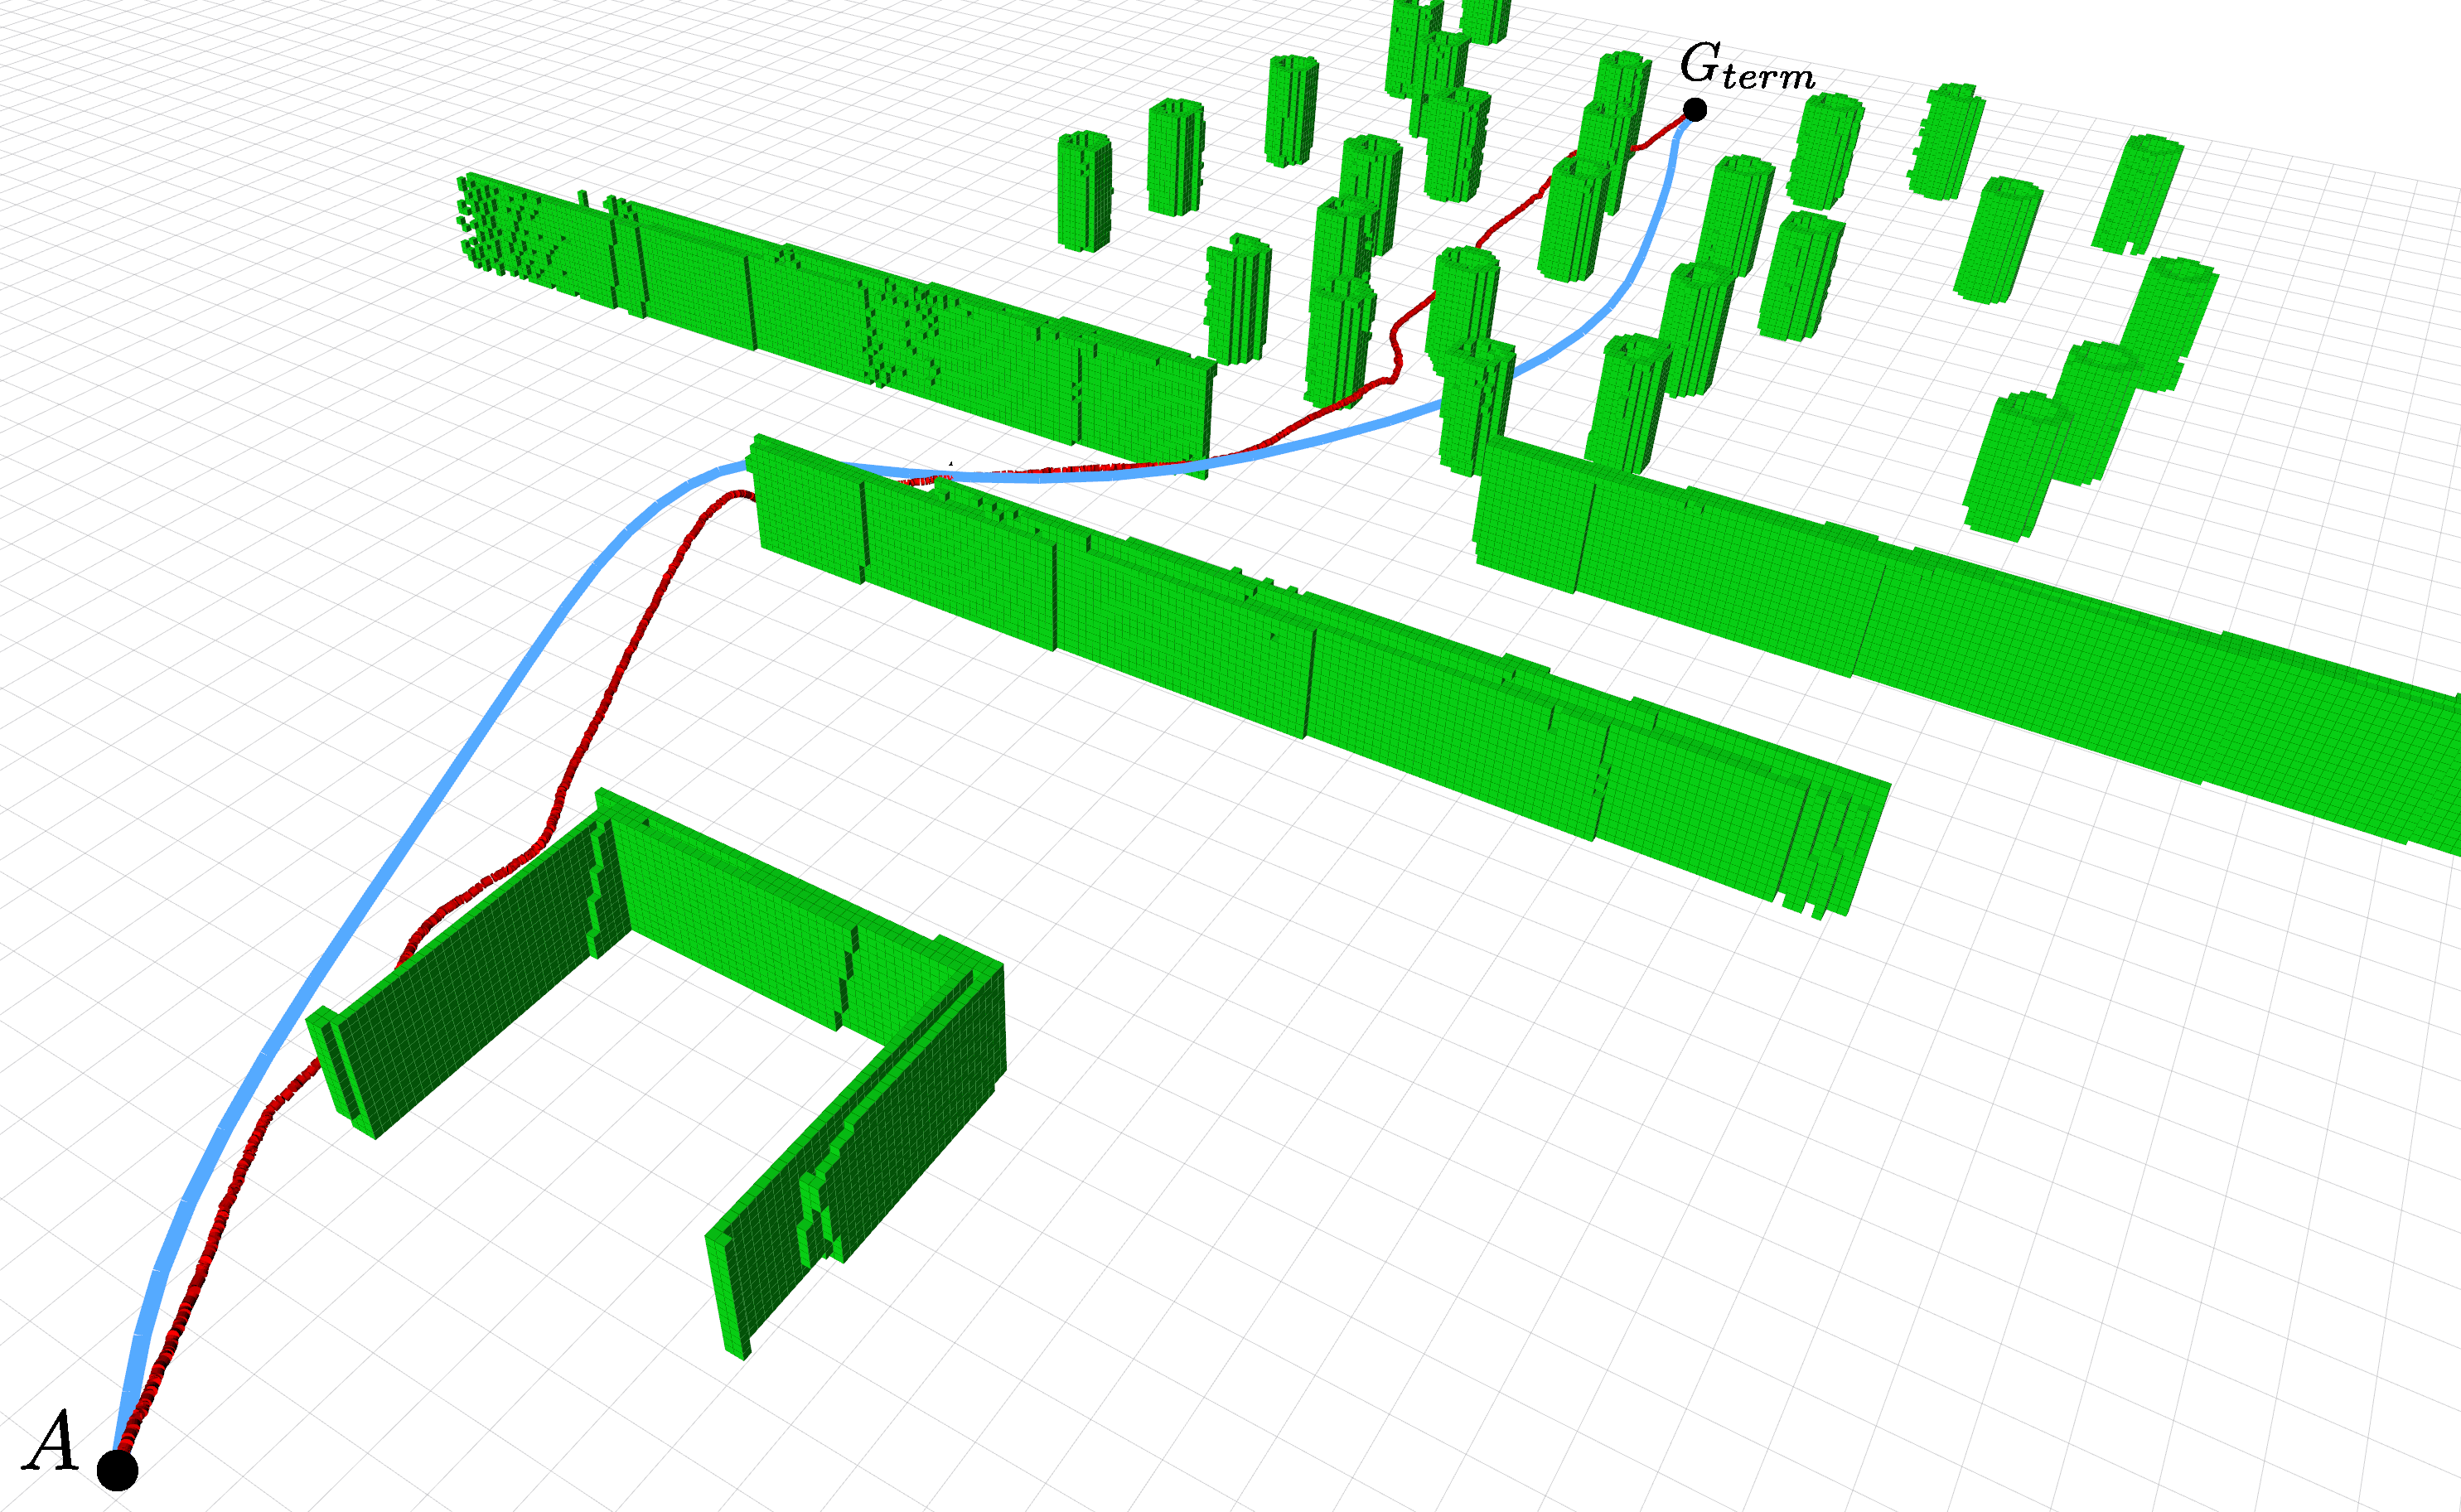 | Real-time Planning and Obstacle Avoidance for UAVs
Jesus Tordesillas Torres, Brett Lopez, 2018
This work proposes a planning framework in which multi-fidelity models are used to reduce the discrepancy between the local and global planner. | 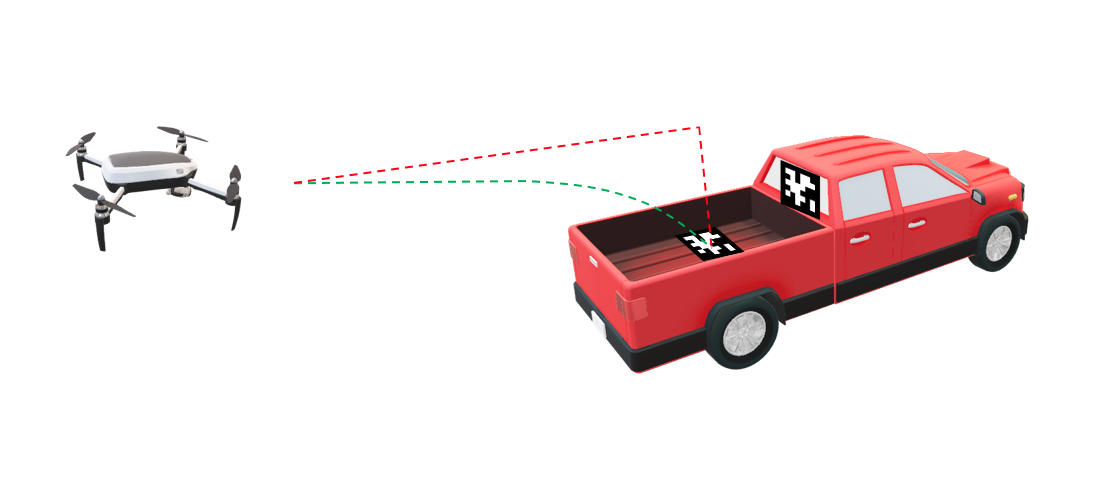 | Integrated Drone Station
Aleix Paris, Brett Lopez, 2018
This project will create effective first/last-mile integrated ground/aerial delivery solutions for a fleet-wide package delivery system. | 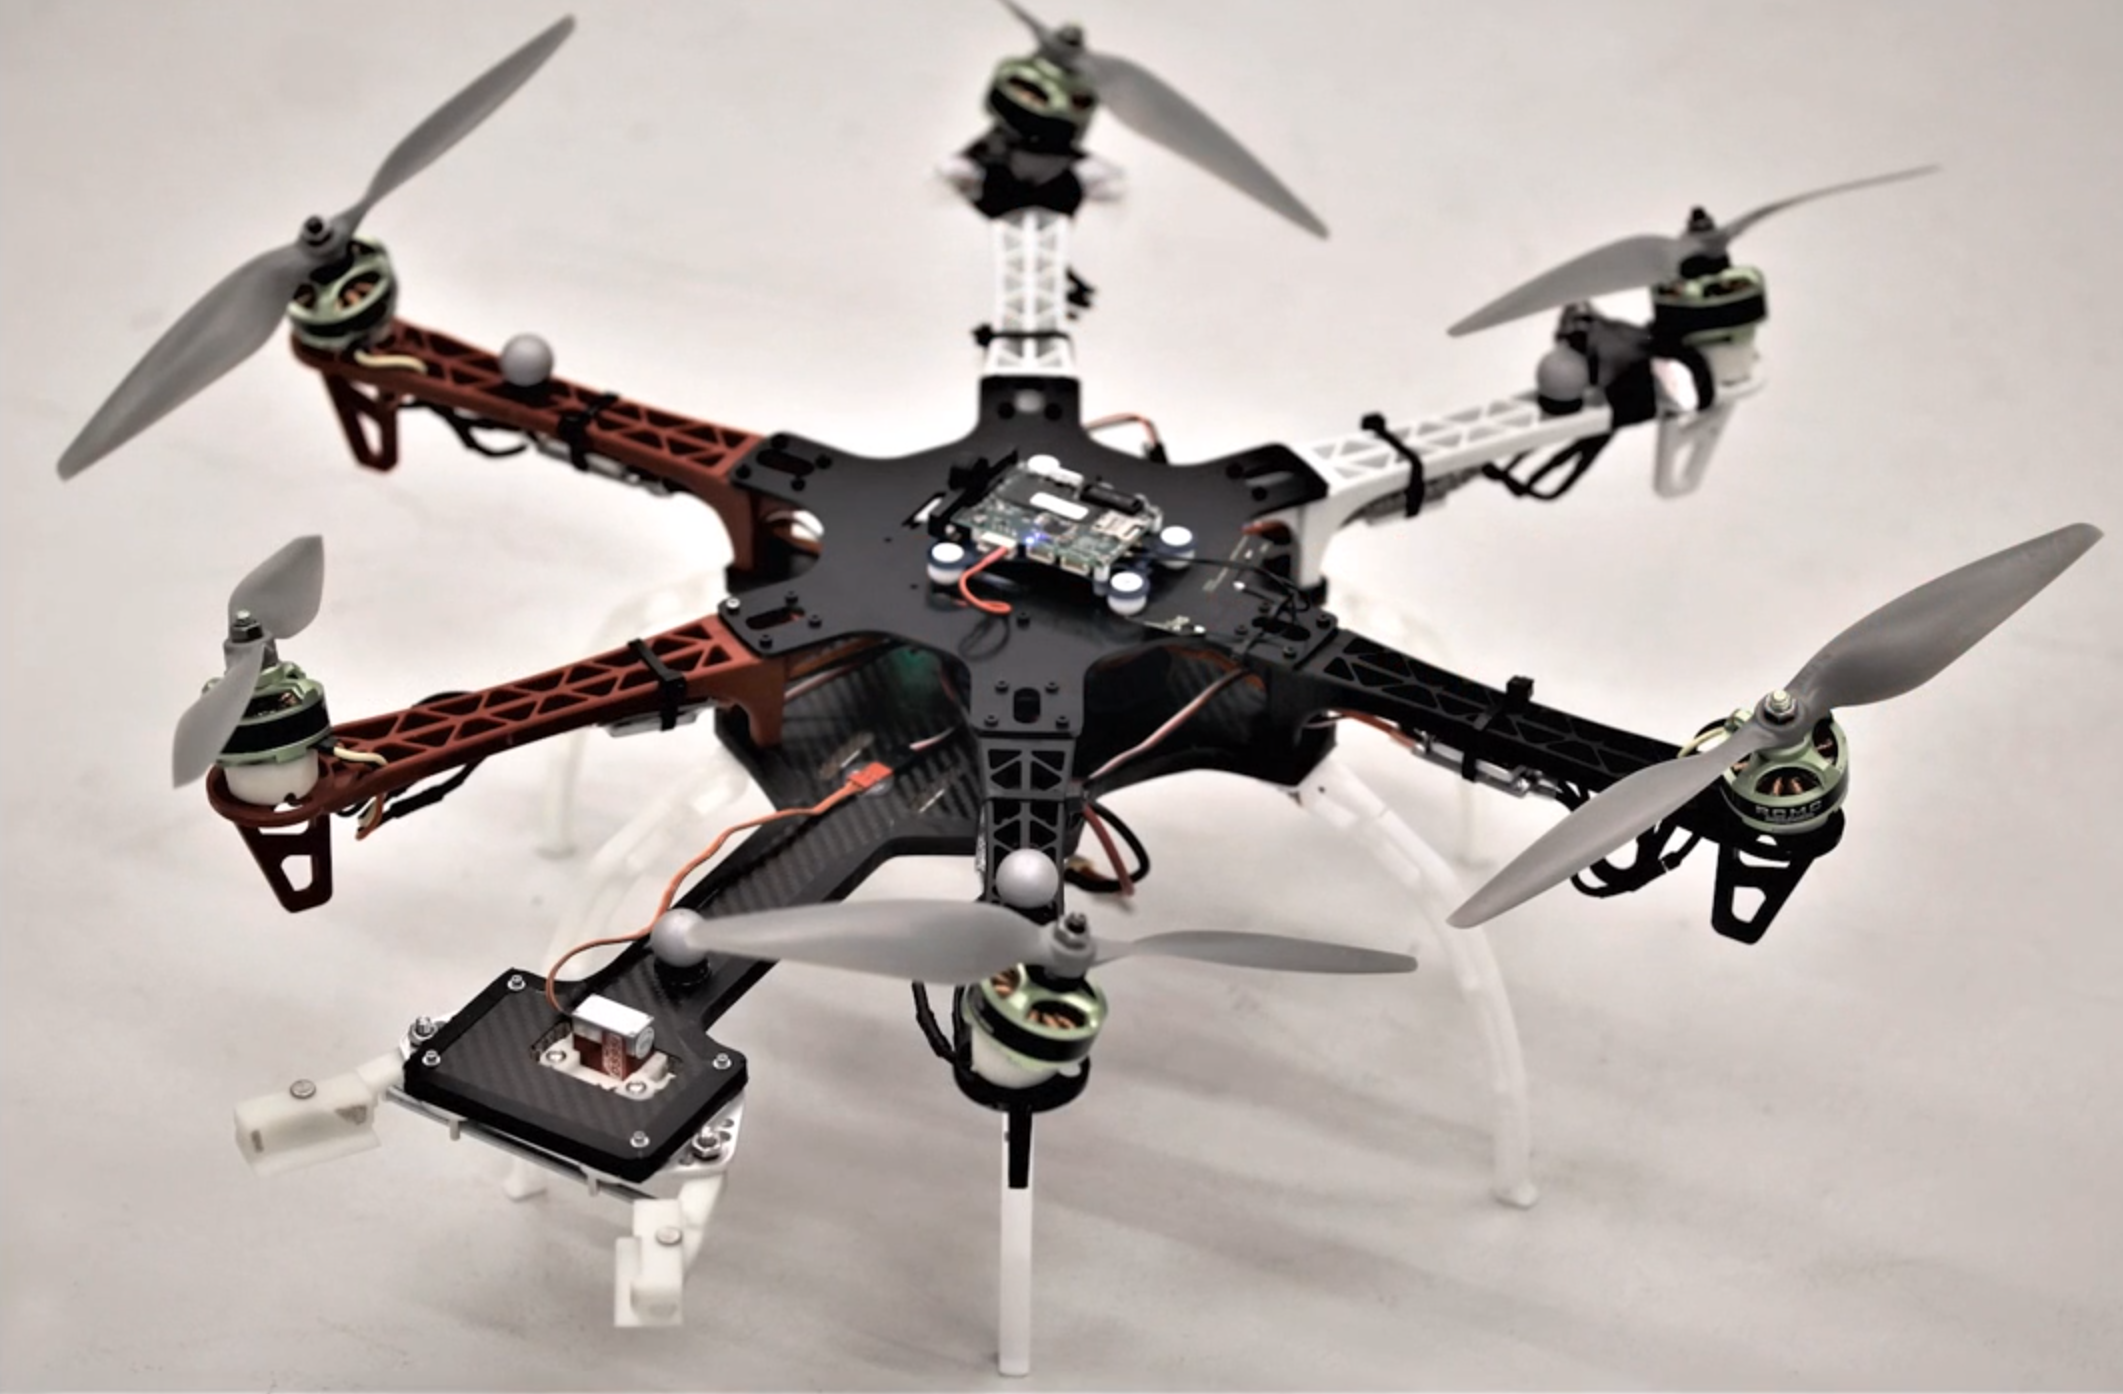 | Agile Plate Transport with a Hexacopter with Canted Motors
Gabriel Bousquet, Jesus Tordesillas Torres, Brett Lopez, 2018
This work proposes the use a Hexacopter with canted motors for precise aerial manipulation tasks. | 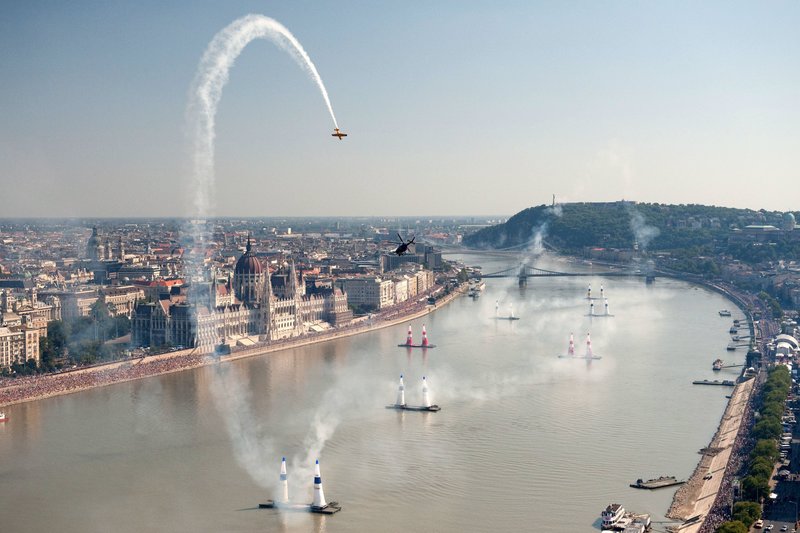 | Indoor Fixed-Wing Aerobatics
Brett Lopez, 2014
The goal of this project is to emulate an air race in a laboratory setting in the hope of expanding control and autonomy paradigms to compensate for unknown system dynamics. | |